

Si deseas distinguir tus productos, servicios o ambos de los de otra empresa, es posible que necesites una marca o nombre comercial. Descubre qué son, en qué consiste su procedimiento de registro y qué implica.

Información sobre los plazos de presentación de solicitudes de transformación de marcas de la Unión Europea en marca nacional española. Más información


Si tienes un nuevo dispositivo, producto o procedimiento que resuelva un problema técnico o tenga una ventaja práctica, existen distintas formas de protegerlo en España y en otros países. Descubre cómo hacerlo.

¿Tu innovación reside en la estética, la ornamentación o la apariencia de tu producto? Protégela mediante un diseño industrial. Descubre qué derechos confiere el registro y cómo realizar la tramitación.

Las indicaciones geográficas protegen el nombre de un producto originario de una zona geográfica, a la cual le debe una determinada calidad, reputación u otra característica. Descubre qué son, en qué consiste su procedimiento de registro y qué beneficios conceden.

Las patentes publicadas en todo el mundo son una valiosa fuente de información científica, técnica y comercial.

Si eres emprendedor/a o una empresa y quieres potenciar y mejorar la rentabilidad de tu negocio protegiendo de forma adecuada los activos intangibles de tu organización, en este espacio encontrarás lo necesario.


 145
resultados
 Última actualización
30/10/2026 [08:19:00]


Resumen de: US20260338753A1
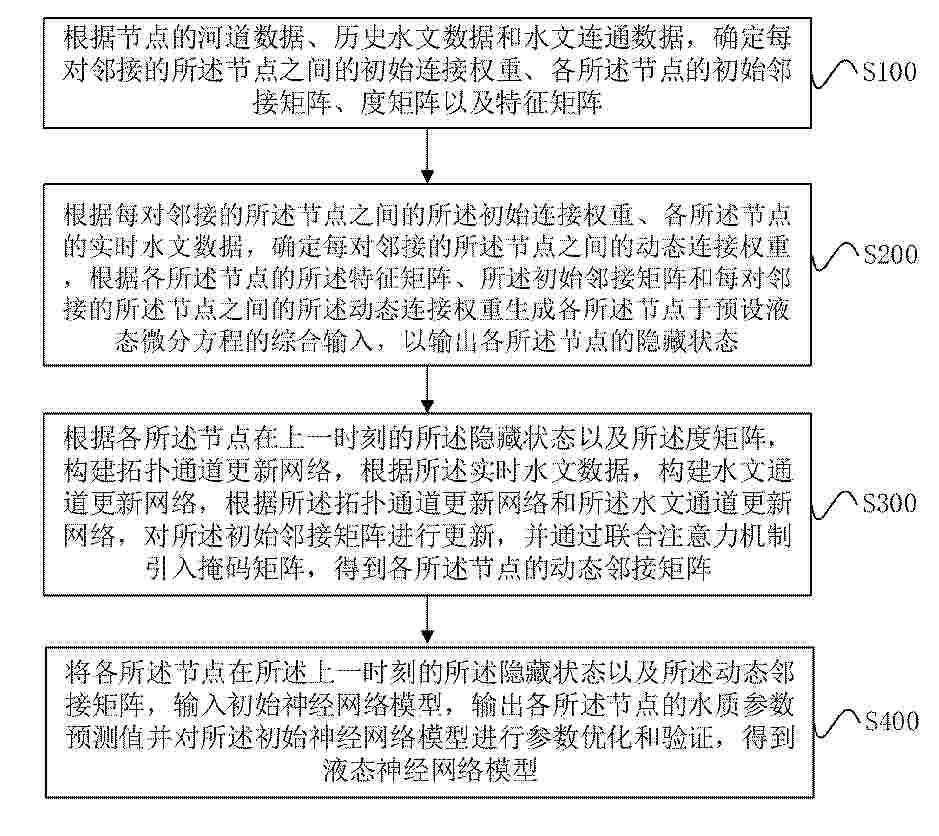
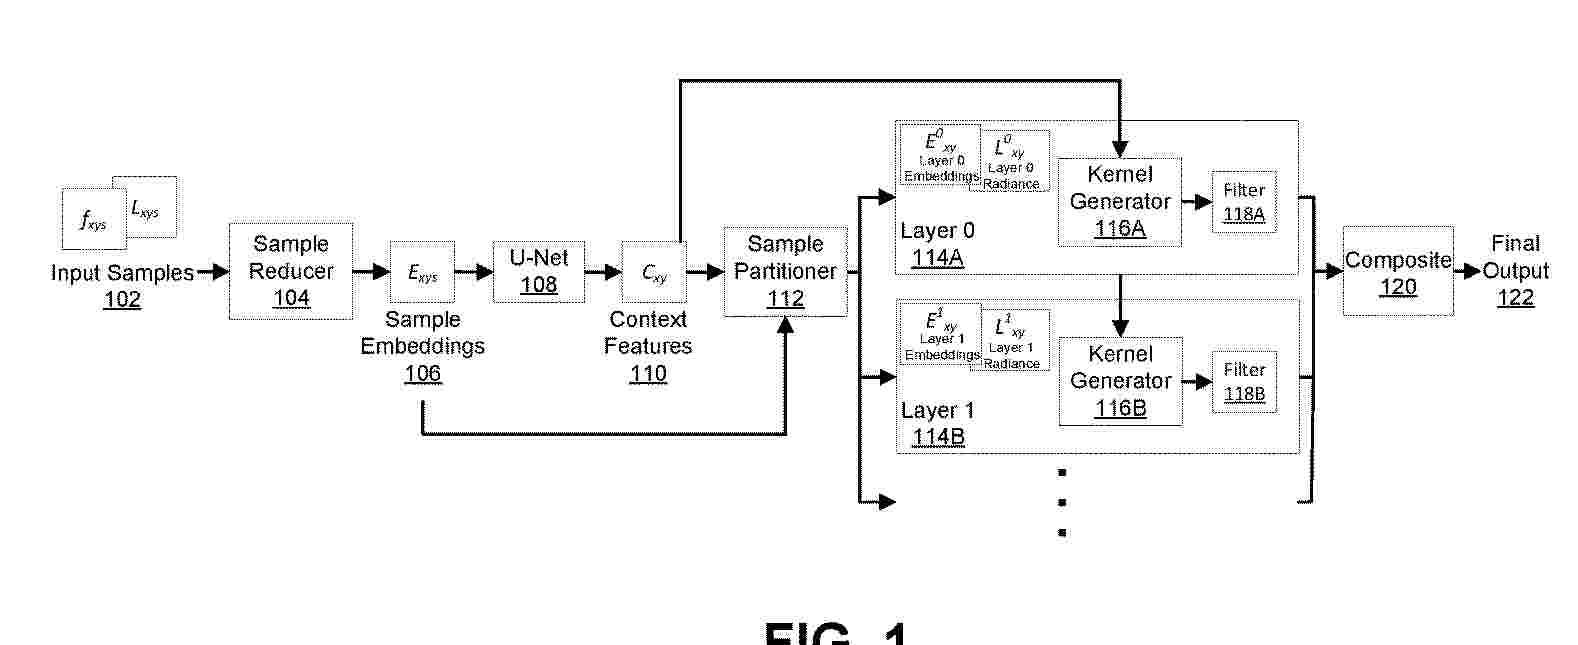
A system for the water quality based on a liquid graph neural network includes watershed front-end monitoring devices, an edge computing apparatus and a central server; the apparatus constructs a directed initial watershed graph, historical flow velocities, a riverbed permeability coefficient and hydrological connectivity data, and dynamically corrects edge weights based on real-time flow velocity gradients and rainfall changes; and generates a dynamic adjacency matrix and outputs predicted values for water quality parameters and alarm levels within a future preset time domain at a data-scarce point by using the neural network; when the predicted value exceeds a preset threshold, the apparatus sends a hardware action instruction to an associated upstream node or downstream node to control an automatic sampler to perform encrypted sampling, and calls a local model and locally cached data to maintain continuous early warning when a response delay of the central server reaches a preset condition.

Resumen de: US20260341003A1
An interactive image generation method receives a communication that requests that a described imaginative scenario is generated that is to be embodied by at least one image. The description of the imaginative scenario is interpreted by applying attentions in association with applying a trained neural network that is trained using a training set comprising syntactical elements and images. Pixels are generated in accordance with learned training correspondences and the imaginative scenario by applying the trained neural network. The pixels may be further generated in accordance with an inference of a user preference that is based on usage behaviors that occur prior to the communication. An image that includes the generated pixels is provided to a user.
Resumen de: US20260341158A1
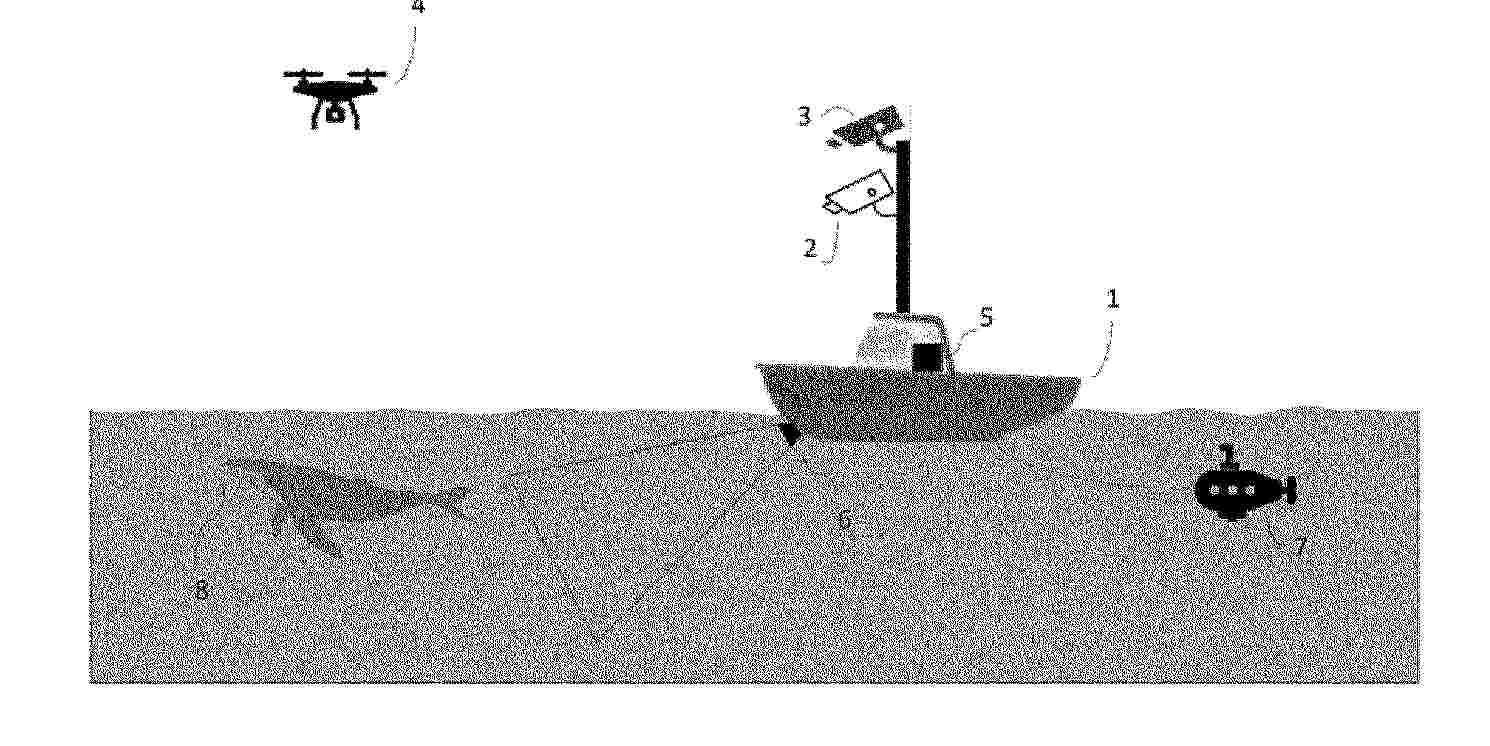
Marine detection system and method for detecting marine bodies (8). The system includes a first sensor (6) for detecting marine bodies in a first detection region. A second sensor (3) is provided for detecting marine bodies in a second detection region. The second sensor is a different type of sensor to the first sensor and the second detection region overlaps with or is adjacent to the first. A controller (5) is provided including a neural network for processing data from the first and second sensors, where the neural network is trained to determine the presence of a marine body (8) based on the sensor data characteristics, and a signal indicating the presence of the marine body is output based on the determination by the neural network.
Resumen de: US20260339628A1
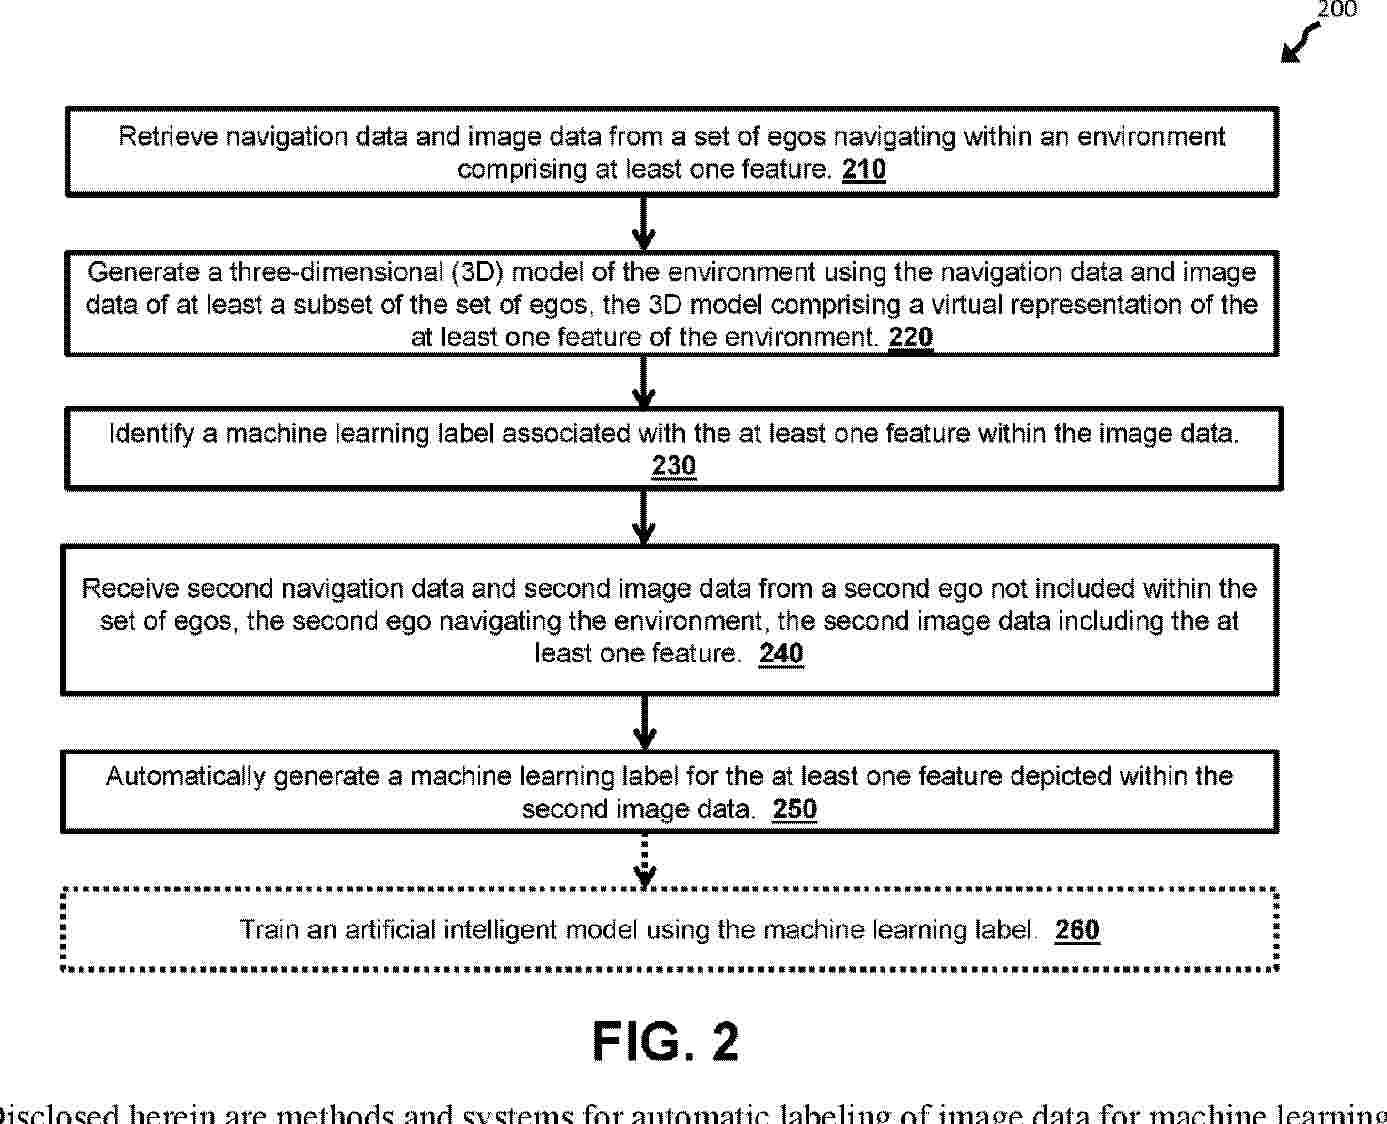
Embodiments include systems and methods for processing sensor data and generating operational instructions of hardware of egos (e.g., autonomous vehicles, robots). The ego includes any number of machine-learning architectures, often neural network architectures, for processing sensor data and recognizing the environment around the ego and making decisions on the ego's behavior. The neural network architectures of the ego ingest sensor data and execute any number of operations related to a particular domain or task, such as object recognition or path planning, using the sensor data. A graph partitioner is trained to assign functions in the software of the neural networks and the sensor data to certain hardware processing units. Several compilers are used to generate the instructions based upon the assigned type of processing unit.
Resumen de: US20260340342A1
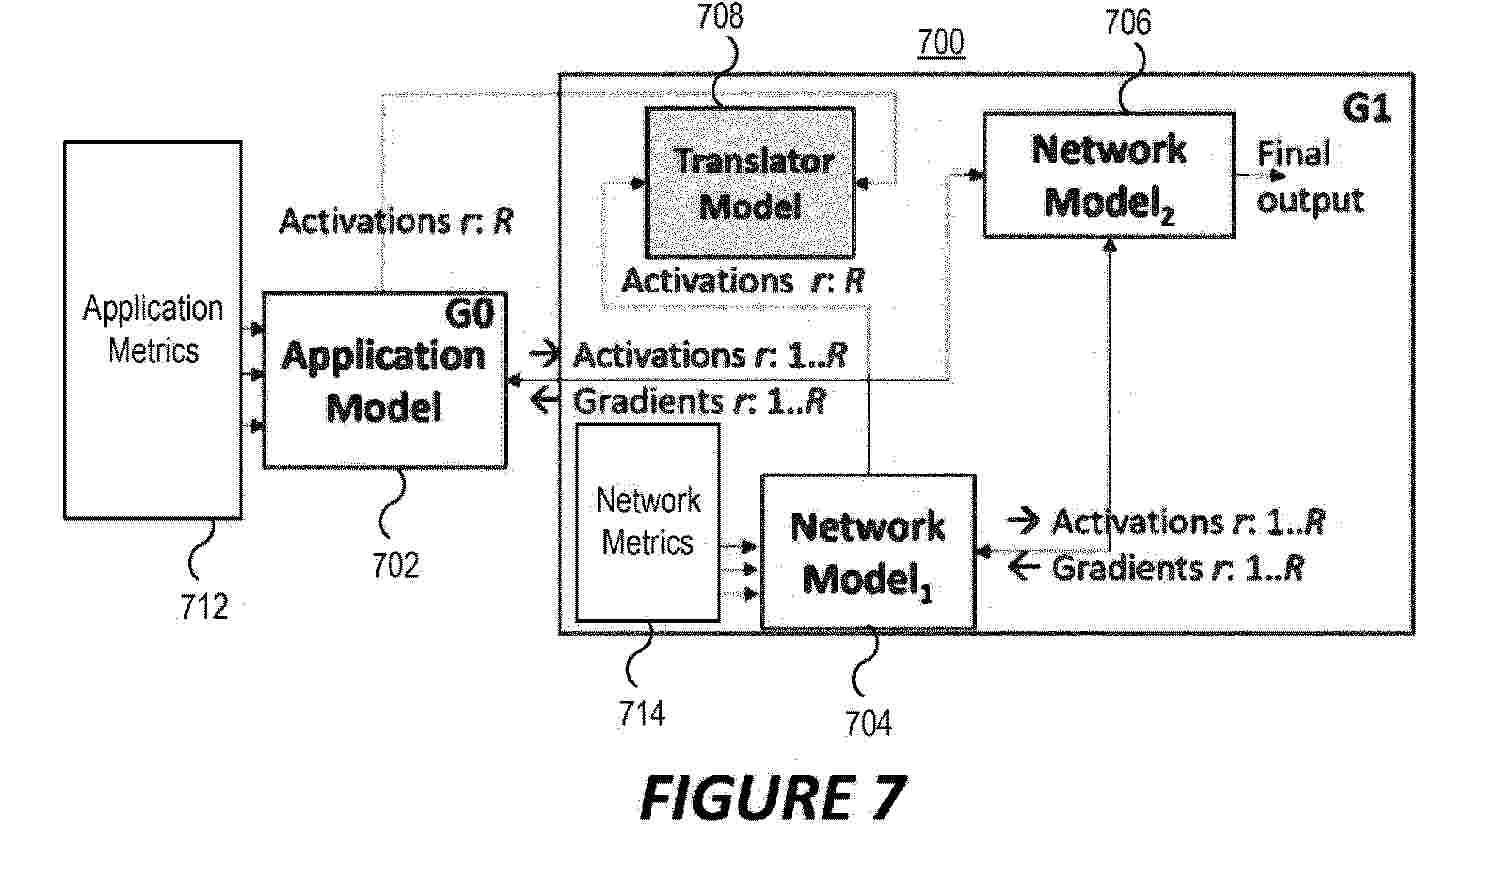
A split neural network includes a tail network model that receives a first plurality of activations and a second plurality of activations at a cut layer of the split neural network, and that generates a model output in response to the first plurality of activations and the second plurality of activations; a head network model that receives a plurality of input feature values and generates the first plurality of activations in response to the plurality of input feature values and provides the first plurality of activations to the tail network model at the cut layer; and a translator model that receives the first plurality of activations, that generates estimated values of the second plurality of activations in response to the first plurality of activations, and that provides the estimated values of the second plurality of activations to the tail network model at the cut layer.
Resumen de: US20260340353A1
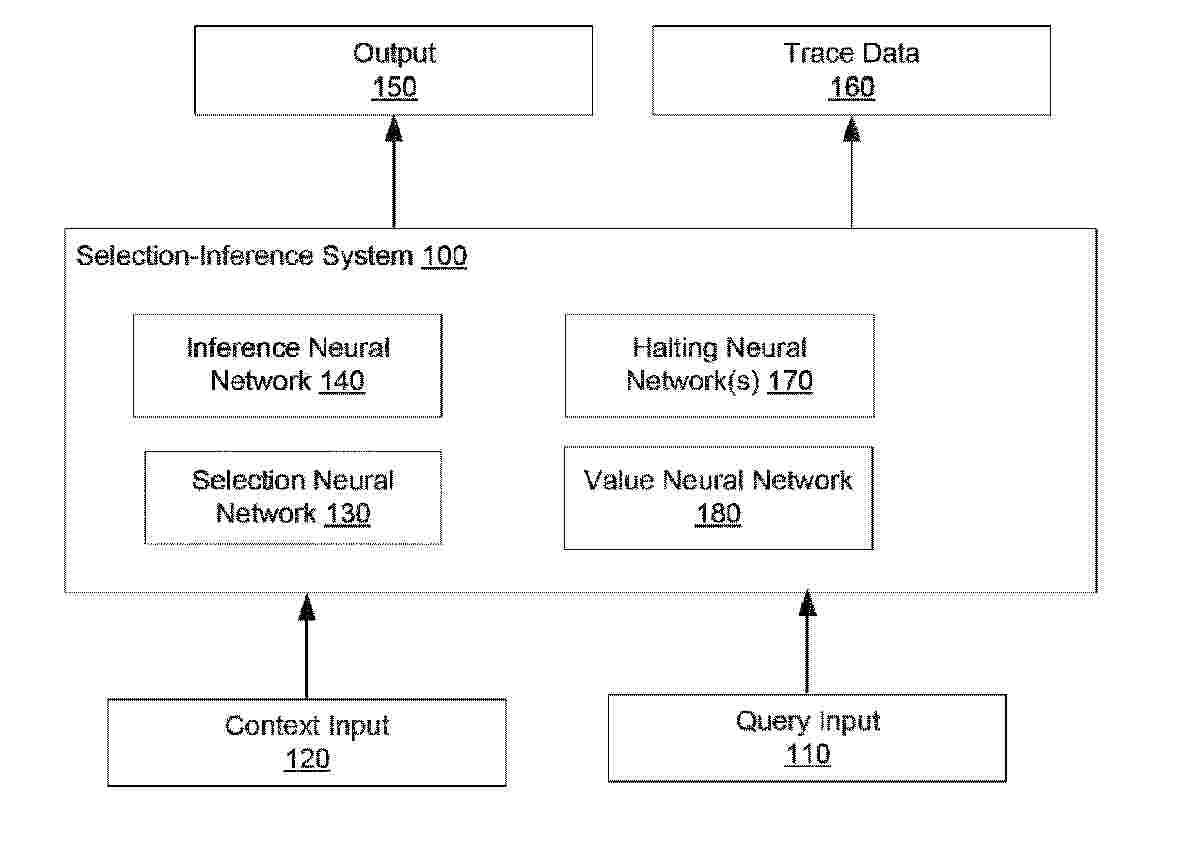
Methods, systems, and apparatus, including computer programs encoded on a computer storage medium, for generating a response to a query input using a selection-inference neural network.
Resumen de: US20260340929A1
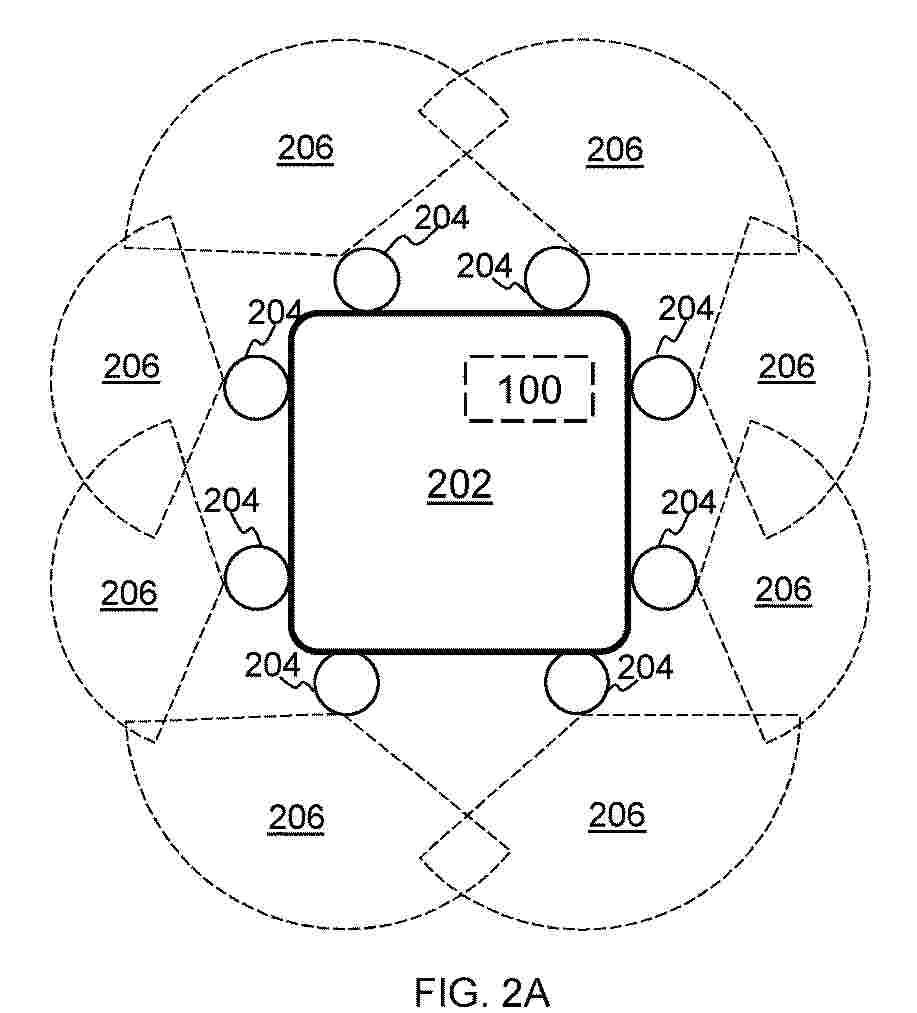
According to various embodiments, a computer-implemented method for generating an outsider perspective image may be provided. The method may include receiving a plurality of input images that capture surroundings of an object. The method may further include projecting each input image of the plurality of input images, onto a respective virtual surface of a set of virtual surfaces around the object to generate a set of surface images. The method may further include projecting each surface image of the set of surface images onto a common coordinate frame, to generate a transformed dataset. The method may further include generating, by a machine learning model, an outsider perspective image based on the transformed dataset.
Resumen de: US20260340766A1
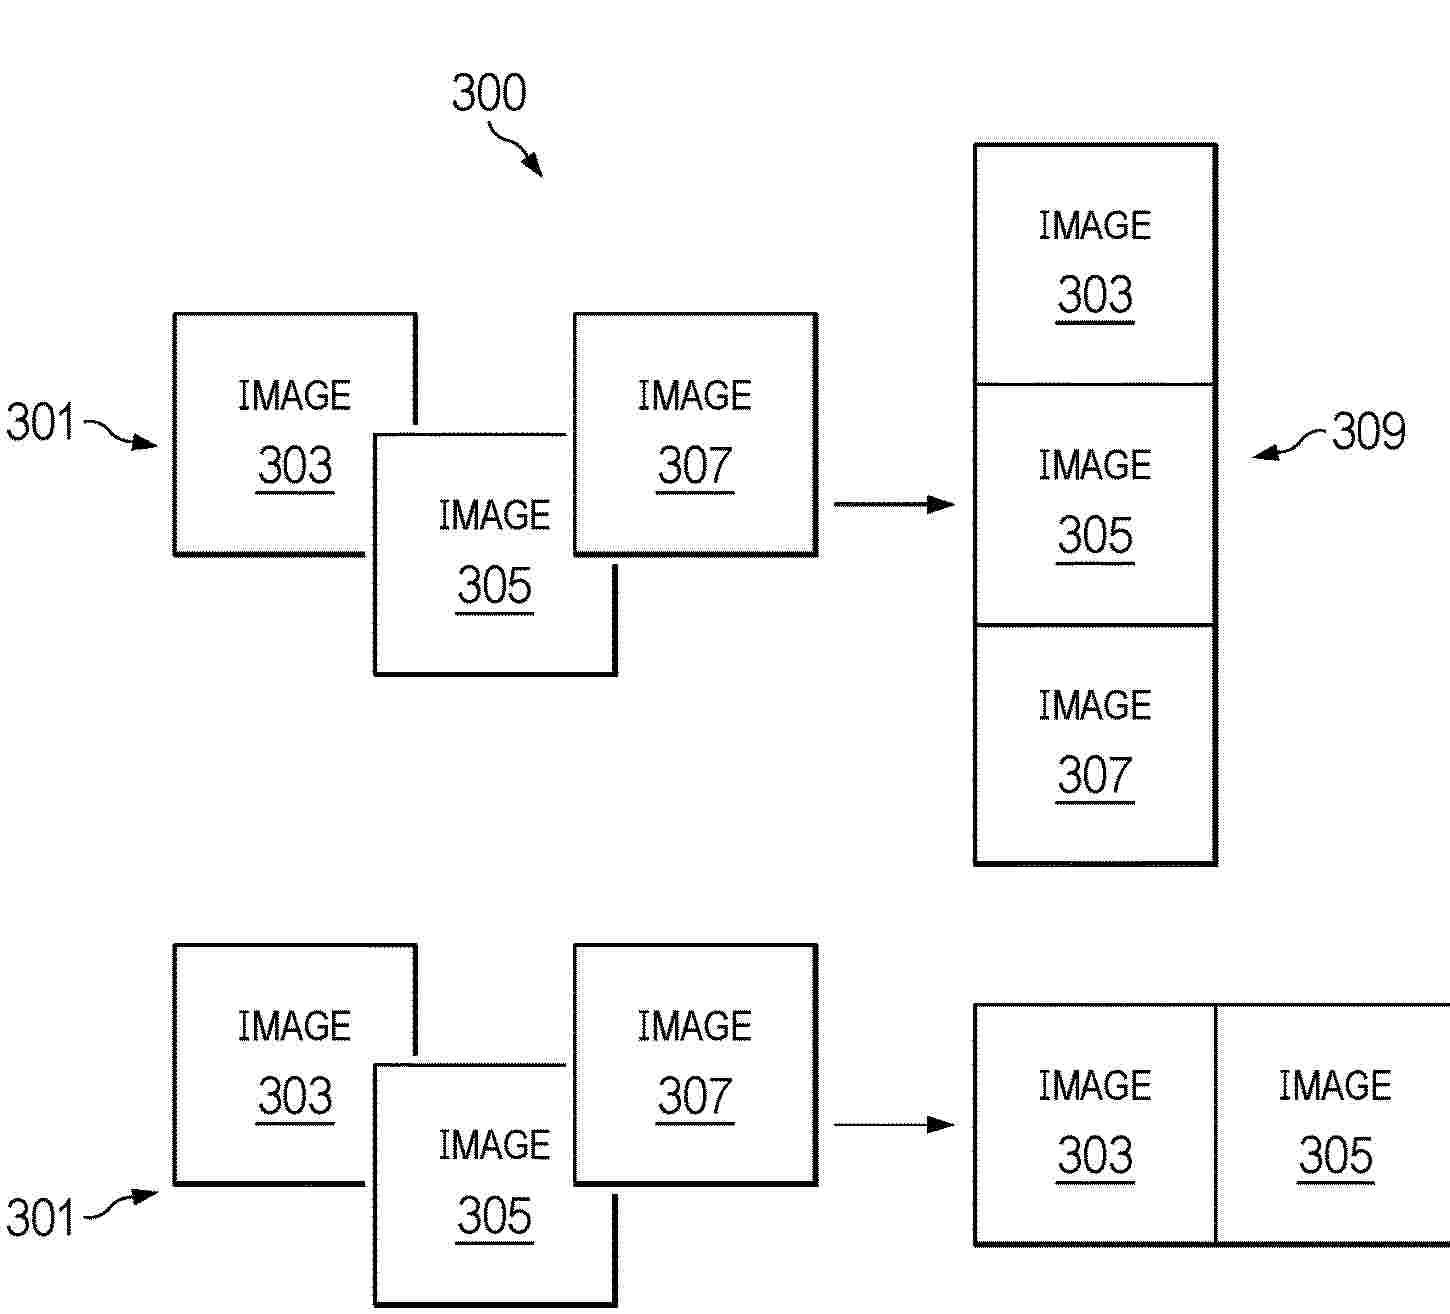
Technology is disclosed herein to execute an inference model by a processor which includes a reshape layer. In an implementation, the reshape layer of the inference model receives an output produced by a previous layer of the inference model and inserts padding into the output, then supplies the padded output as an input to a next layer of the inference model. In an implementation, the inference model includes a stitching layer at the beginning of the inference model and an un-stitch layer at the end of the model. The stitching layer of the inference model stitches together multiple input images into an image batch and supplies the image batch as an input to a subsequent layer. The un-stitch layer receives output from a penultimate layer of the inference model and unstitches the output to produce multiple output images corresponding to the multiple input images.
Resumen de: US20260339634A1
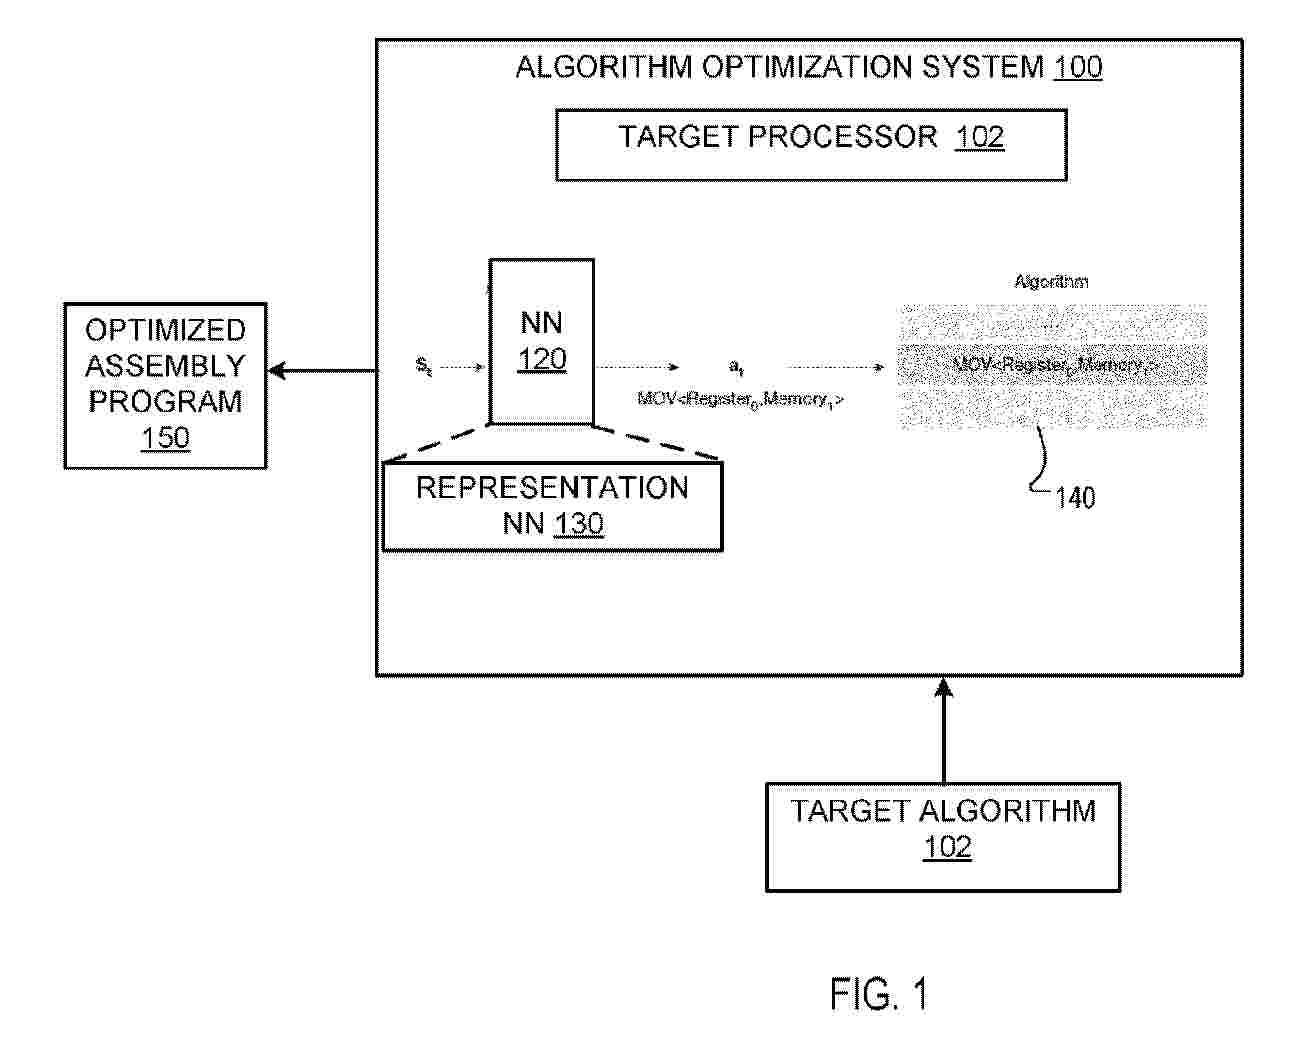
Methods, systems, and apparatus, including computer programs encoded on computer storage media, for optimizing a target algorithm using a state representation neural network.
Resumen de: US20260340783A1
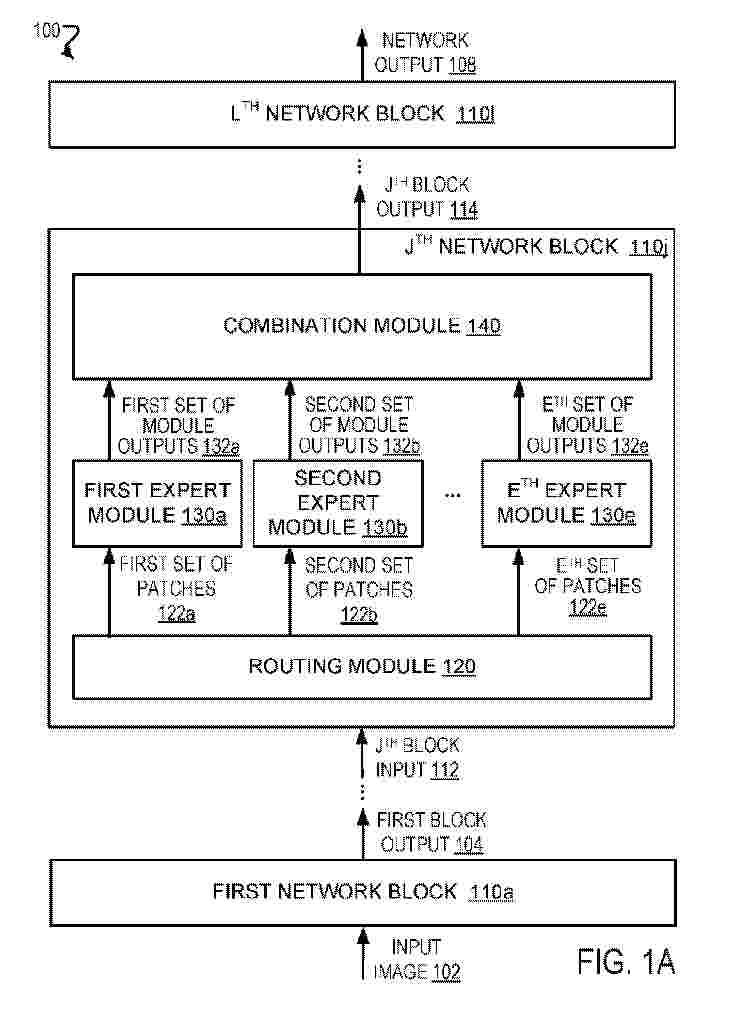
Methods, systems, and apparatus, including computer programs encoded on computer storage media, for generating predictions about images. One of the systems includes a neural network comprising a sequence of one or more network blocks that are each configured to perform operations comprising: obtaining a block input that represents an intermediate representation of an input image; determining a plurality of patches of the block input or of an updated representation of the block input, wherein each patch comprises a different subset of elements of the block input or of the updated representation of the block input; assigning each patch to one or more respective expert modules of a plurality of expert modules of the network block; for each patch of the plurality of patches, processing the patch using the corresponding expert modules to generate respective module outputs; and generating a block output by combining the module outputs.
Resumen de: US20260340378A1
A data processing system for training a neural network. The data processing system comprises a storage circuitry configured to store checkpoint data for training the neural network and training configuration data indicative of a data partition for training the neural network. The data processing system also comprises a processing circuitry configured to perform a checkpoint operation for a layer of the neural network. The checkpoint operation comprises: obtaining input feature map data for a layer of the neural network, obtaining the training configuration data, selecting a portion of the input feature map data based on the training configuration data, processing the selected input feature map data in the layer of the neural network to obtain output feature map data, selecting a portion of the output feature map data based on the training configuration data, and storing, in the storage circuitry, checkpoint data derived from the selected output feature map data.
Resumen de: US20260340809A1
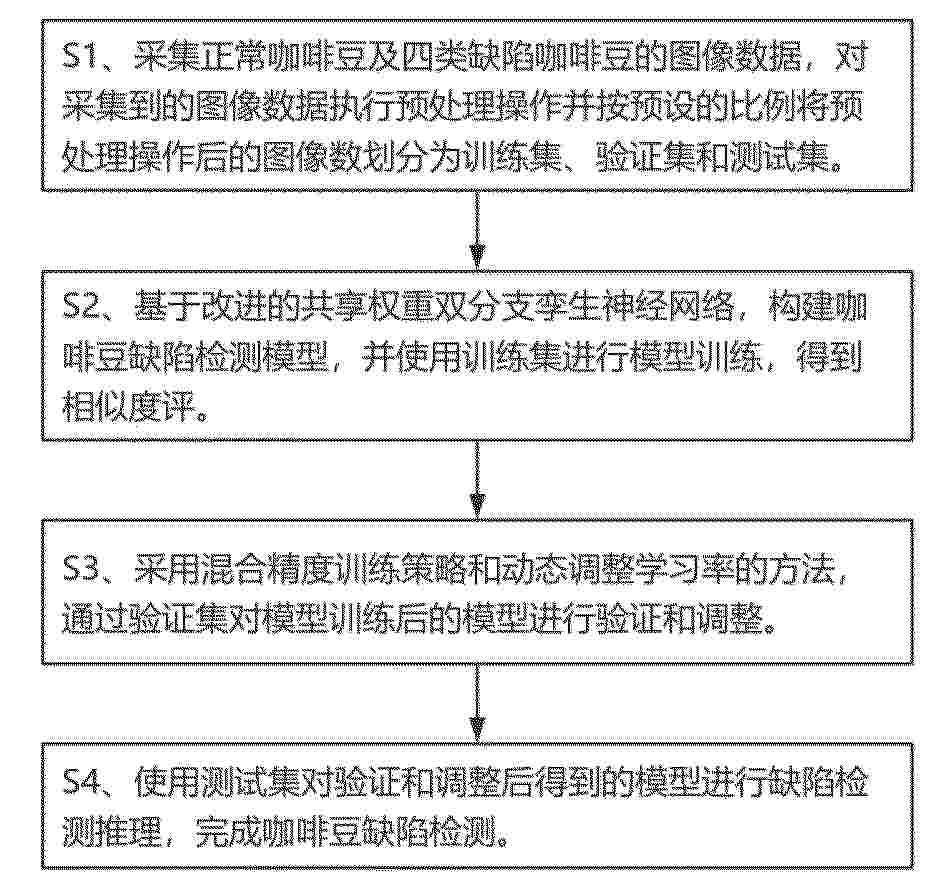
Disclosed is a method for coffee bean defect detection based on a Siamese neural network. The method includes: obtaining image data of normal coffee beans and four types of defective coffee beans, performing a preprocessing operation on the image data, and dividing the preprocessed image data into a training set, a validation set, and a test set according to a preset ratio; constructing a coffee bean defect detection model based on a dual-branch Siamese neural network, and training the coffee bean defect detection model using the training set to obtain a similarity score; validating and adjusting the trained coffee bean defect detection model using the validation set by employing a mixed-precision training strategy and a dynamic learning rate adjustment technique; and performing defect detection inference on the validated and adjusted coffee bean defect detection model using the test set to complete the coffee bean defect detection.
Resumen de: US20260340885A1
Apparatuses, systems, and techniques to identify one or more layers of a three-dimensional graphical image to generate a two-dimensional representation. In at least one embodiment, one or more layers of a three-dimensional graphical image are identified to generate one or more two-dimensional representations.
Resumen de: US20260340979A1
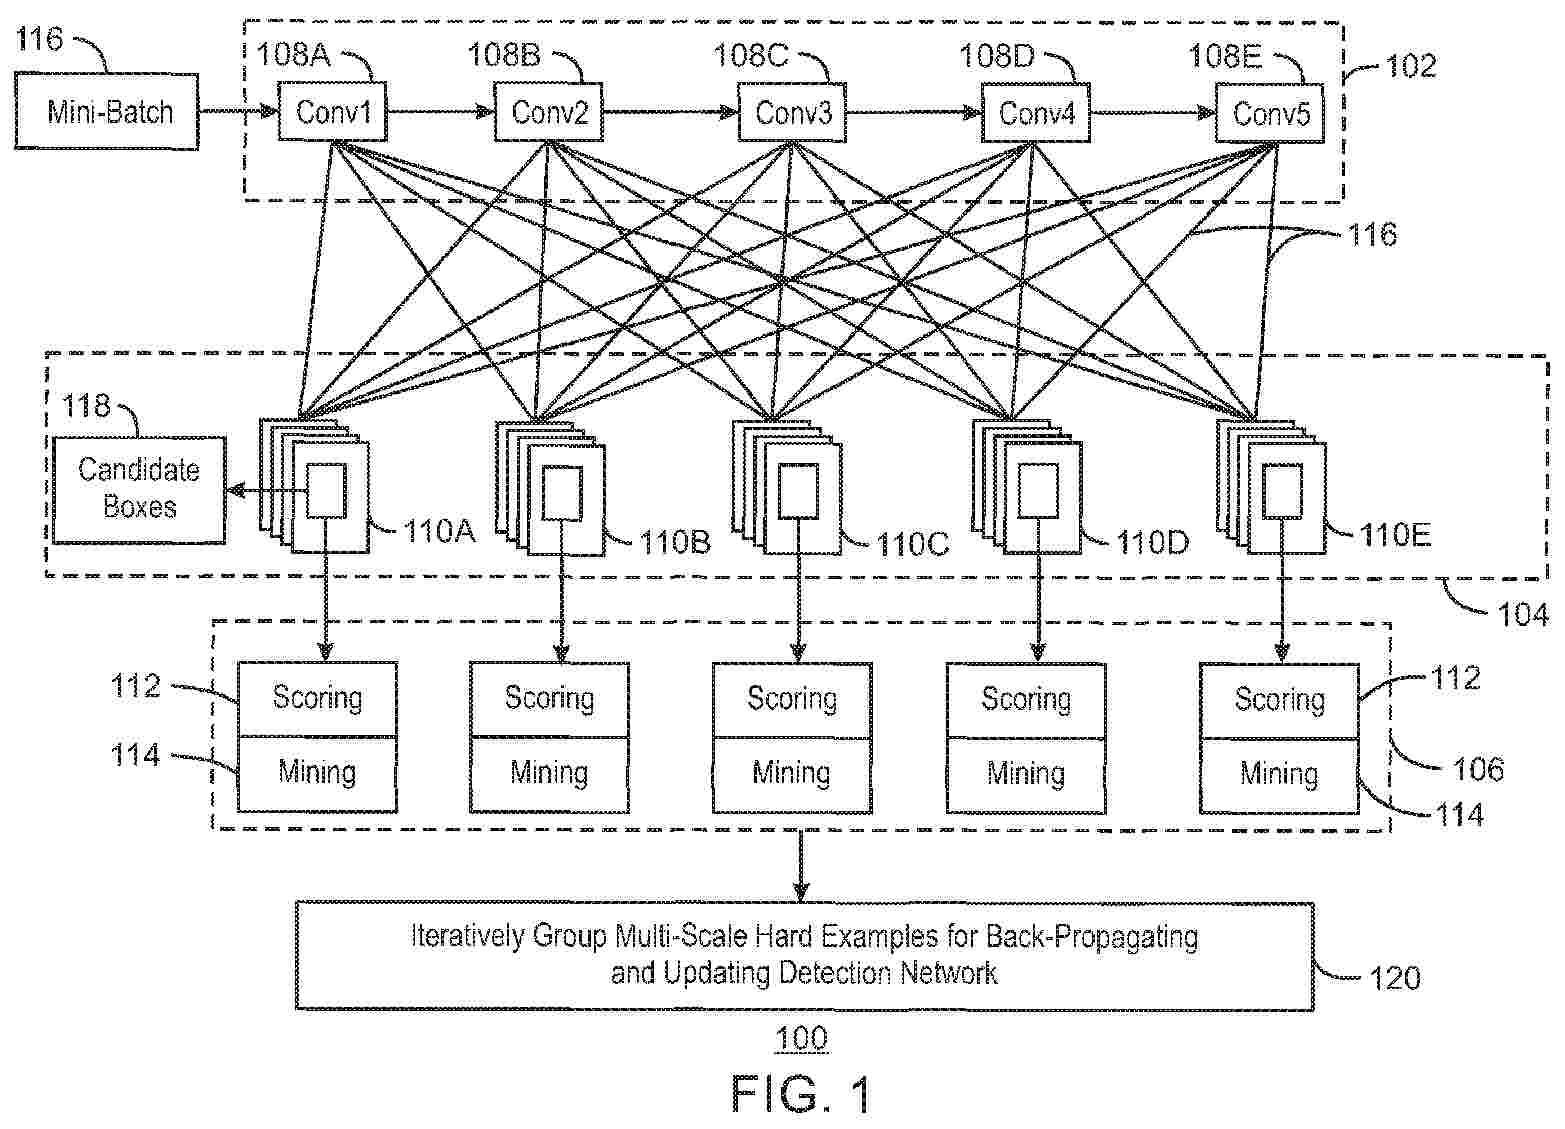
An example apparatus for mining multi-scale hard examples includes a convolutional neural network to receive a mini-batch of sample candidates and generate basic feature maps. The apparatus also includes a feature extractor and combiner to generate concatenated feature maps based on the basic feature maps and extract the concatenated feature maps for each of a plurality of received candidate boxes. The apparatus further includes a sample scorer and miner to score the candidate samples with multi-task loss scores and select candidate samples with multi-task loss scores exceeding a threshold score.
Resumen de: US20260340387A1
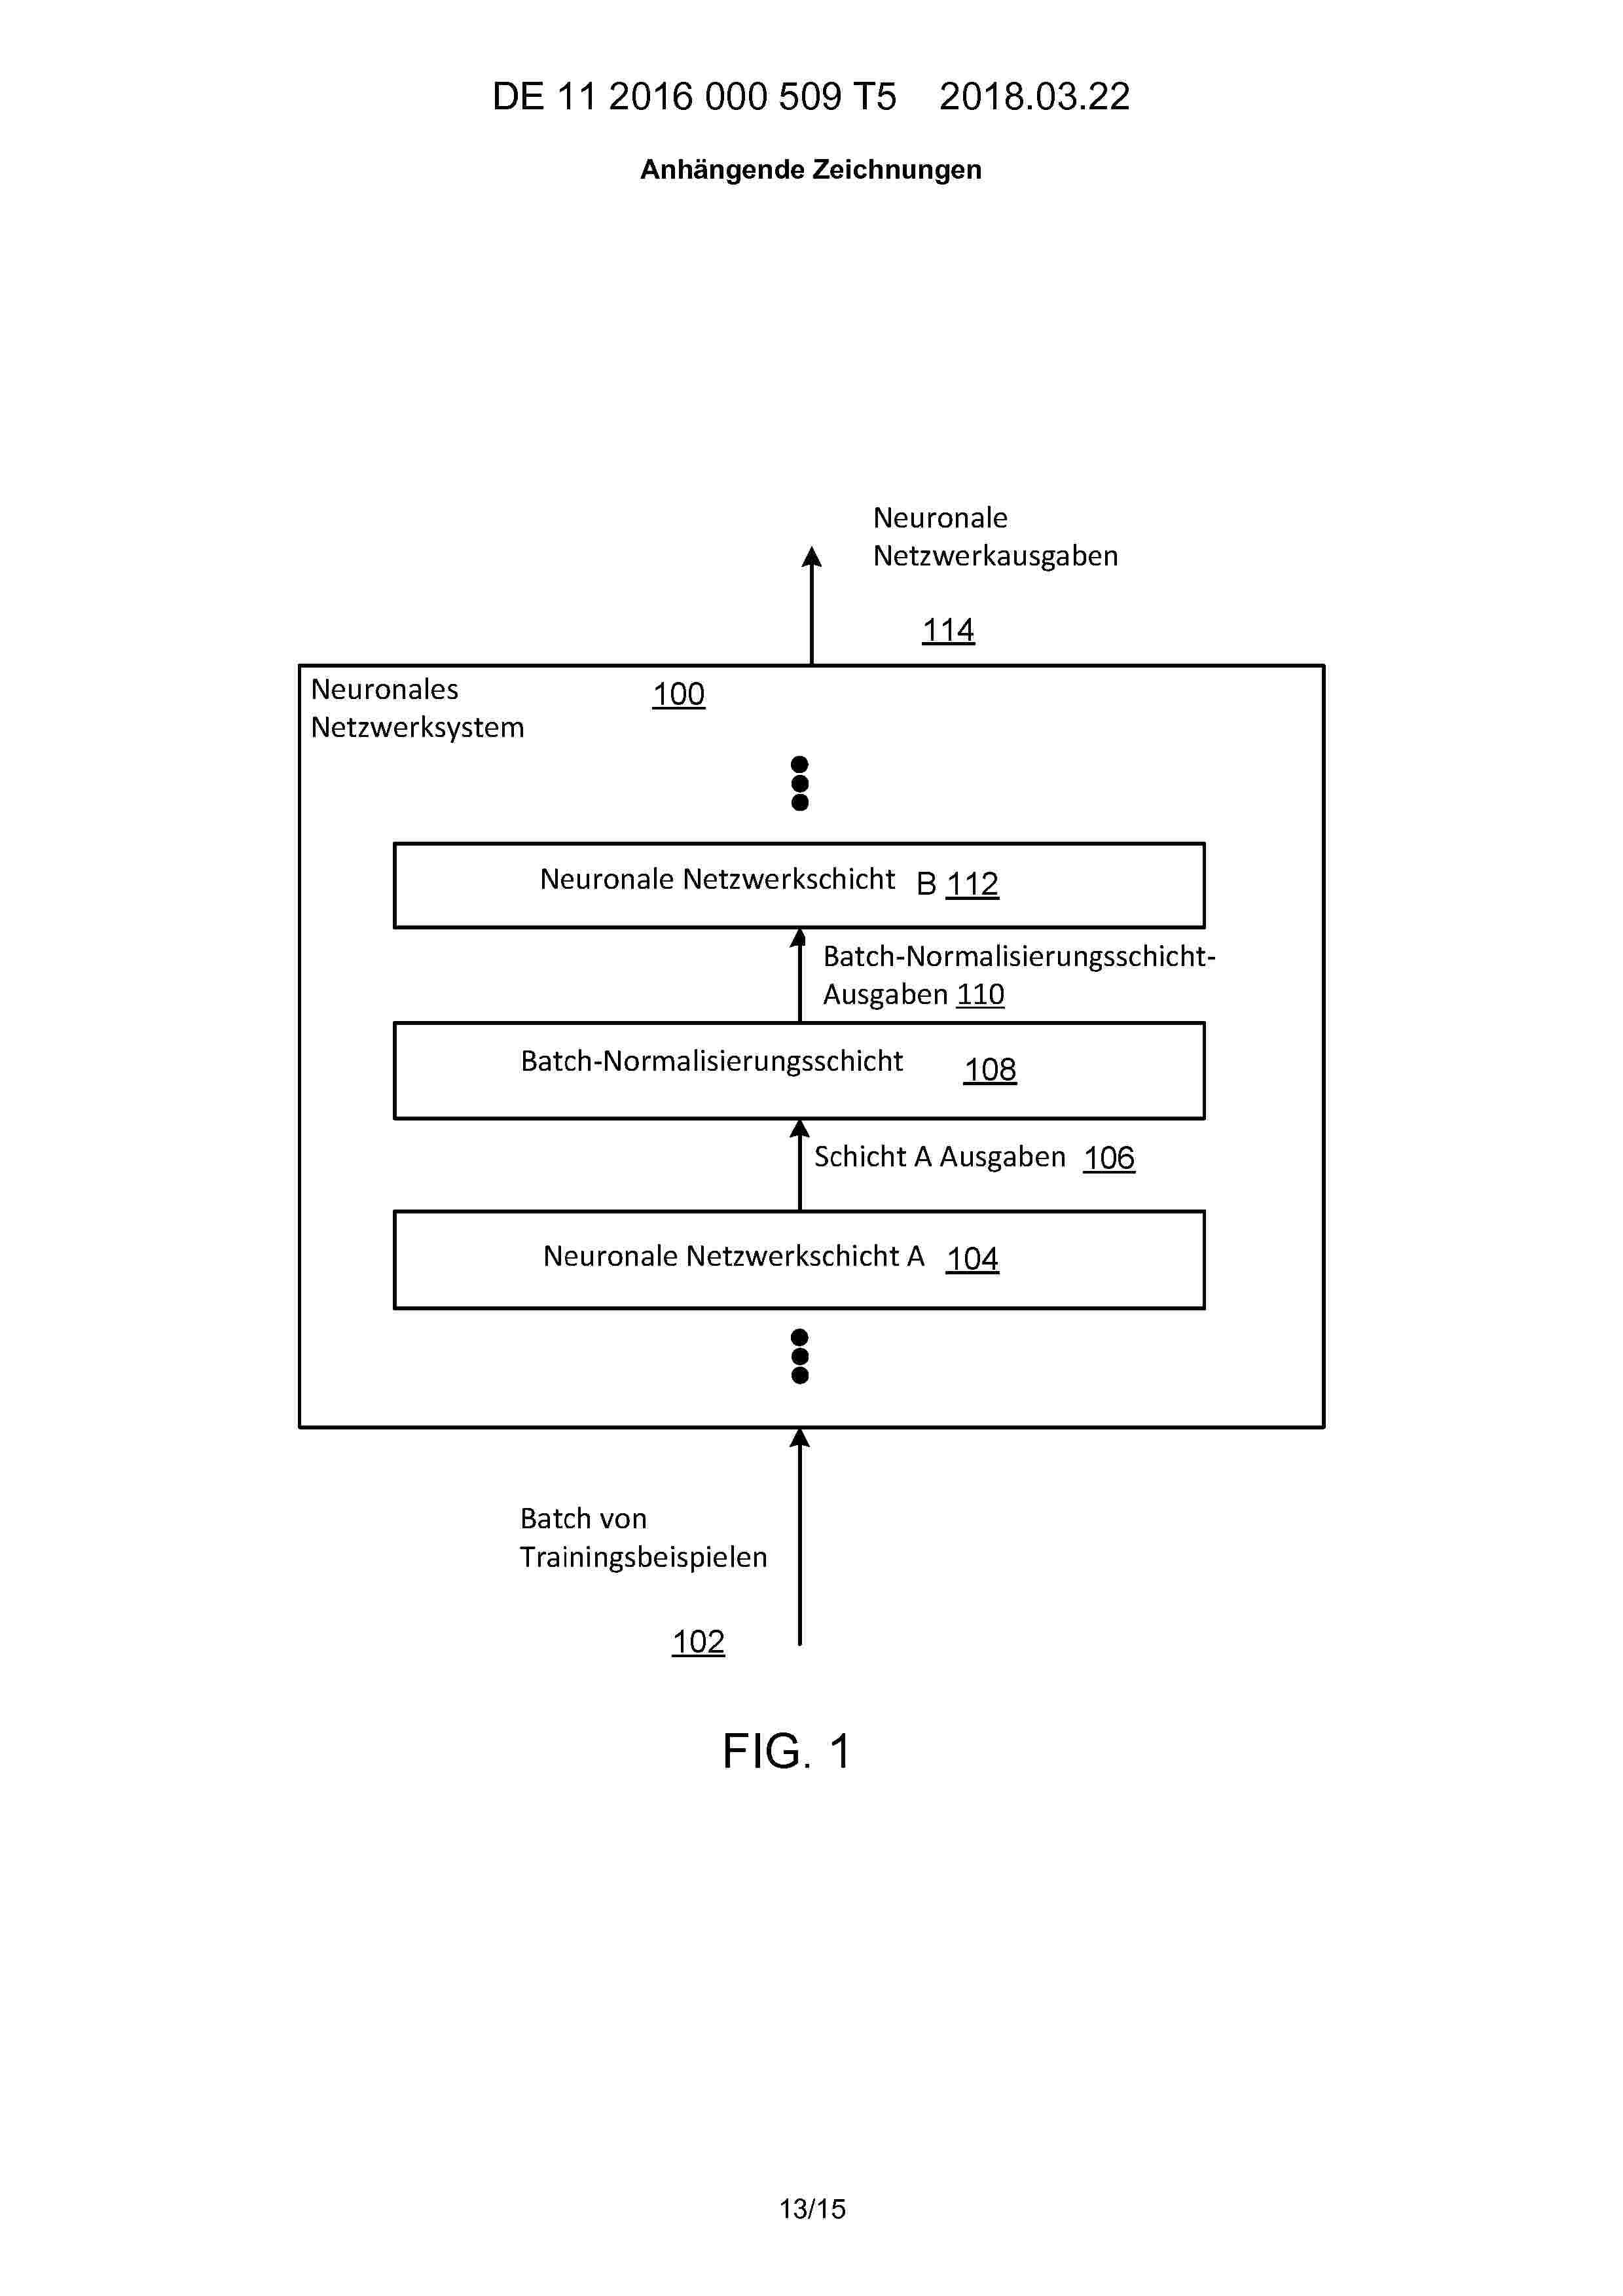
Methods, systems, and apparatus, including computer programs encoded on computer storage media, for processing images or features of images using an image classification system that includes a batch normalization layer. One of the systems includes a convolutional neural network configured to receive an input comprising an image or image features of the image and to generate a network output that includes respective scores for each object category in a set of object categories, the score for each object category representing a likelihood that that the image contains an image of an object belonging to the category, and the convolutional neural network comprising: a plurality of neural network layers, the plurality of neural network layers comprising a first convolutional neural network layer and a second neural network layer; and a batch normalization layer between the first convolutional neural network layer and the second neural network layer.
Resumen de: AU2026253872A1
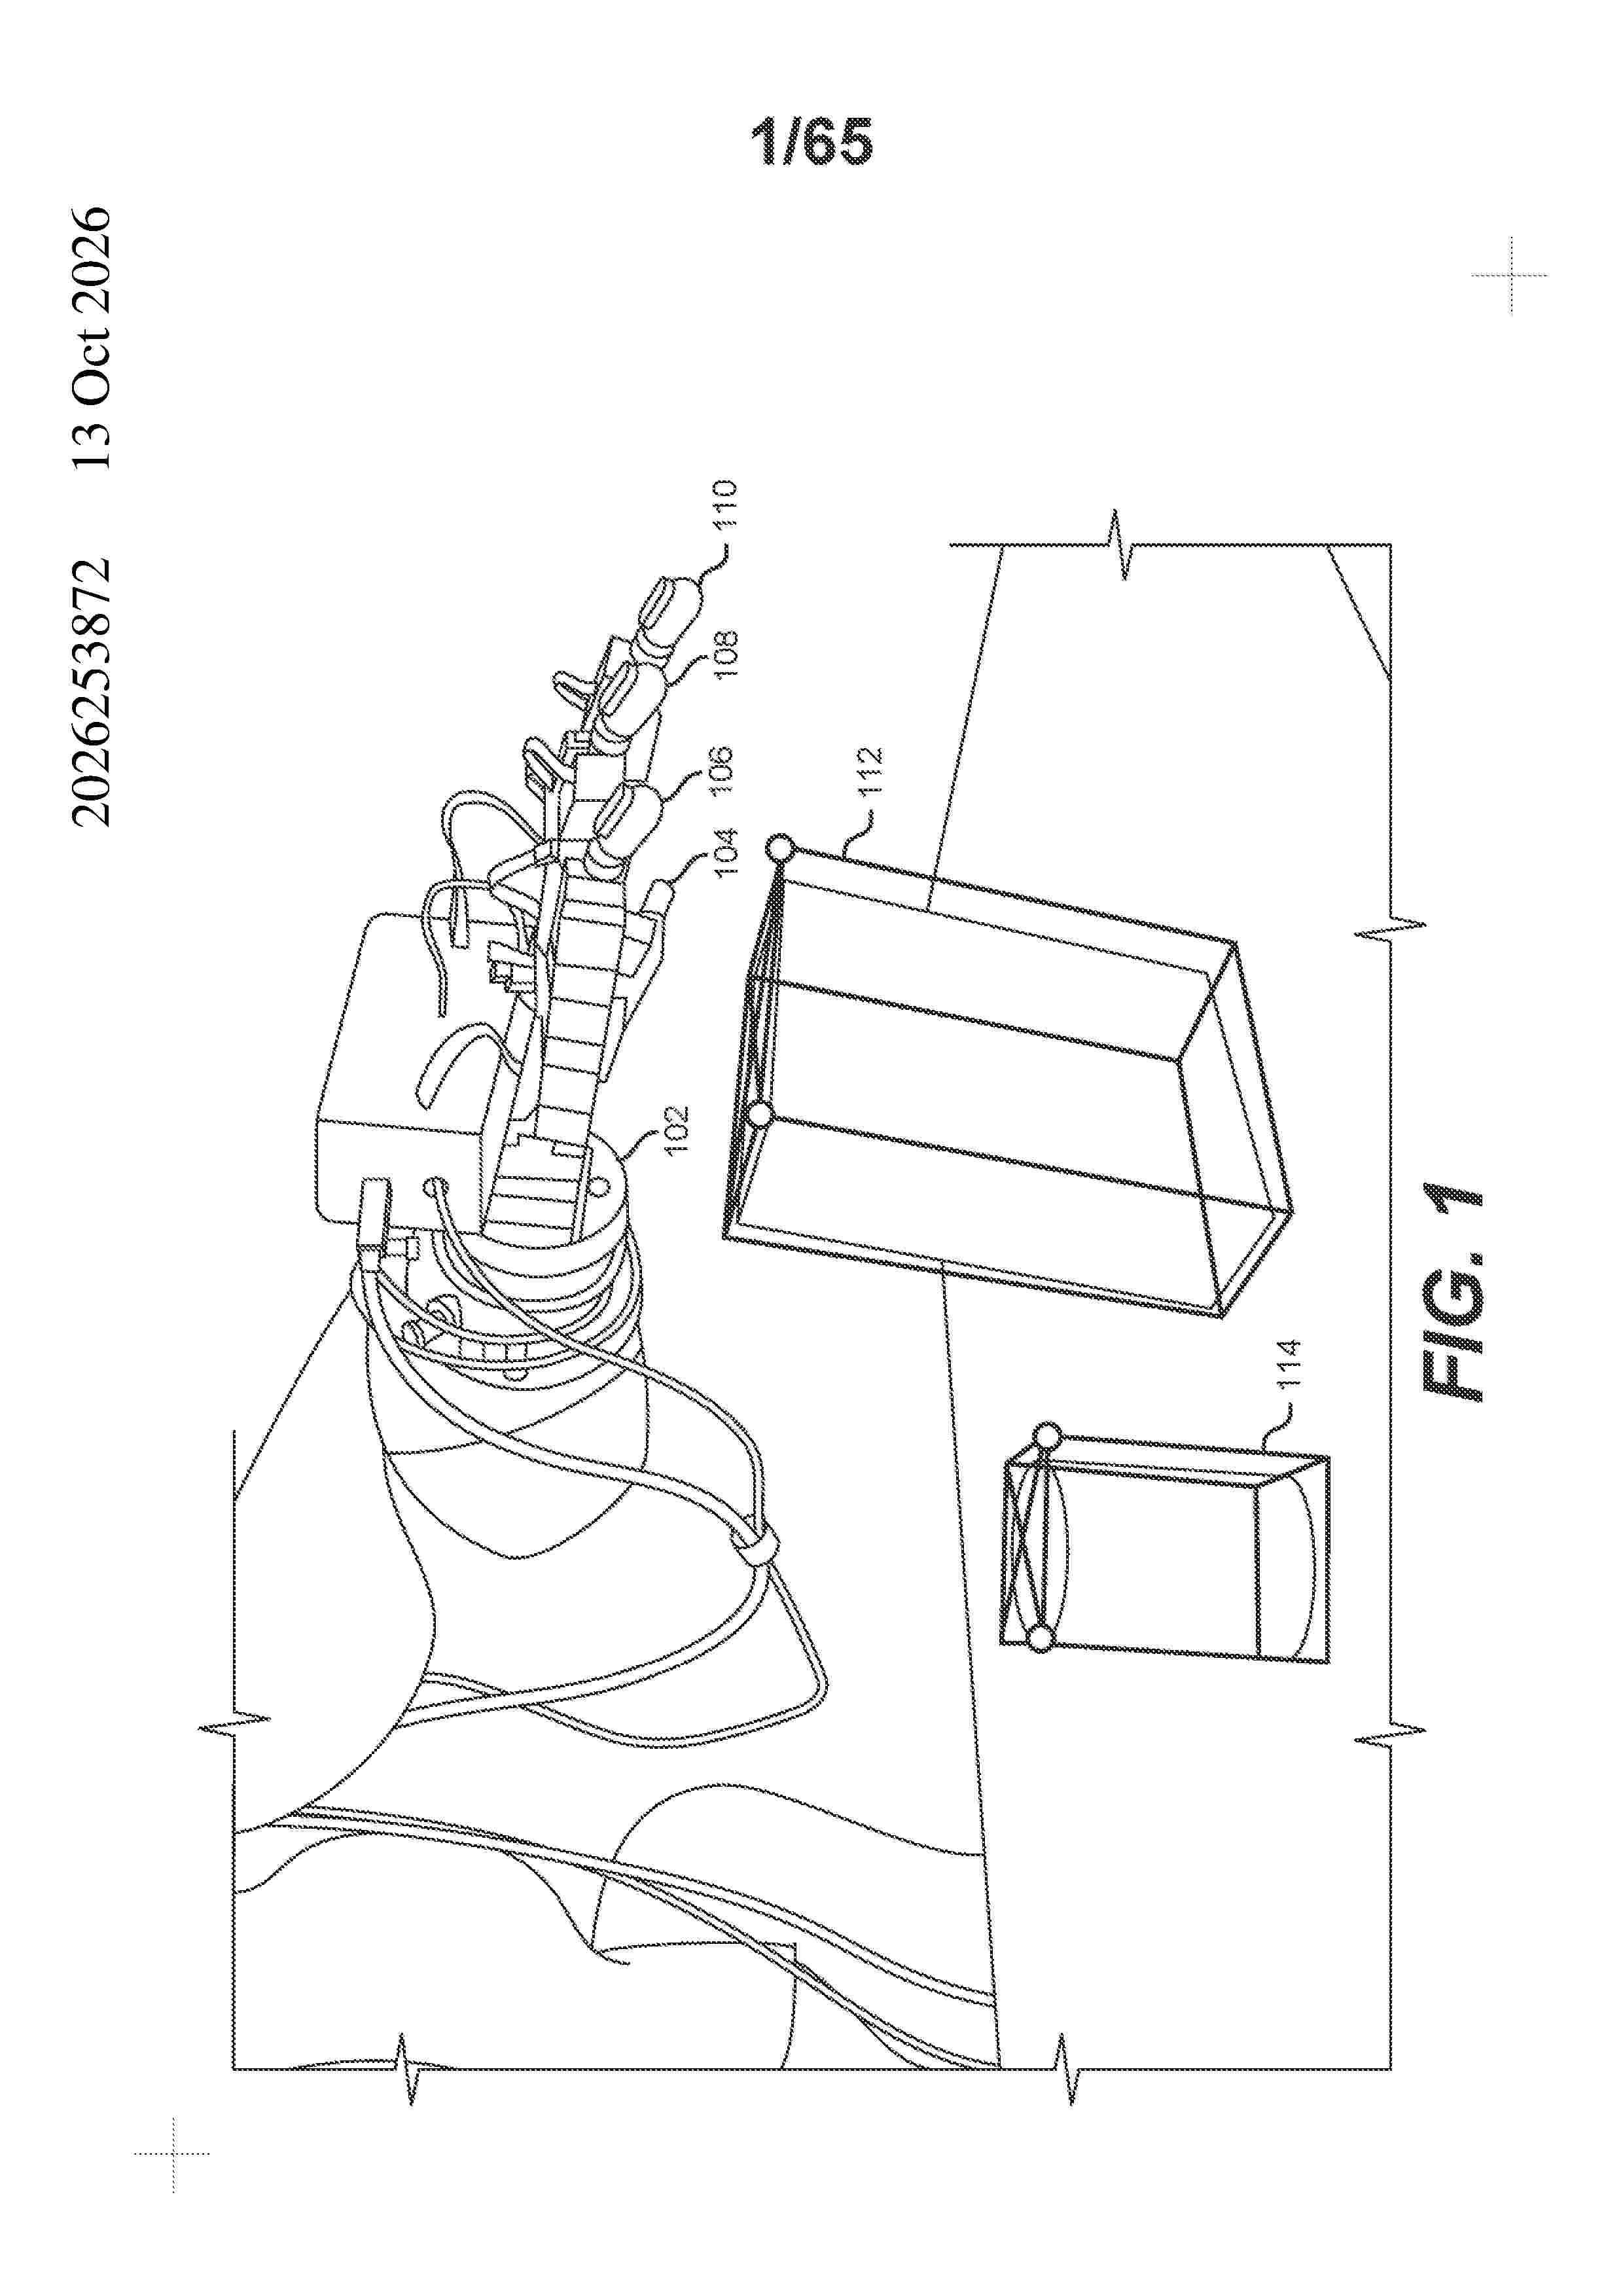
One or more processors comprising: circuitry to enable one or more robotic devices to grasp one or more objects by: identifying, in one or more images depicting a scene that includes the one or more objects, one or more bounding volumes enclosing the one or more objects; using one or more neural networks to identify a target pose of one or more robotic devices to interact with the one or more objects based, at least in part, on one or more measurements from one or more tactile sensors attached to the one or more robotic devices and the bounding volumes enclosing the one or more objects identified in the one or more images; and causing the one or more robotic devices to grasp the one or more objects based, at least in part, on the identified target pose. measurements from one or more tactile sensors attached to the one or more robotic devices ct c t m e a s u r e m e n t s f r o m o n e o r m o r e t a c t i l e s e n s o r s a t t a c h e d t o t h e o n e o r m o r e r o b o t i c d e v i c e s
Resumen de: EP4831848A1
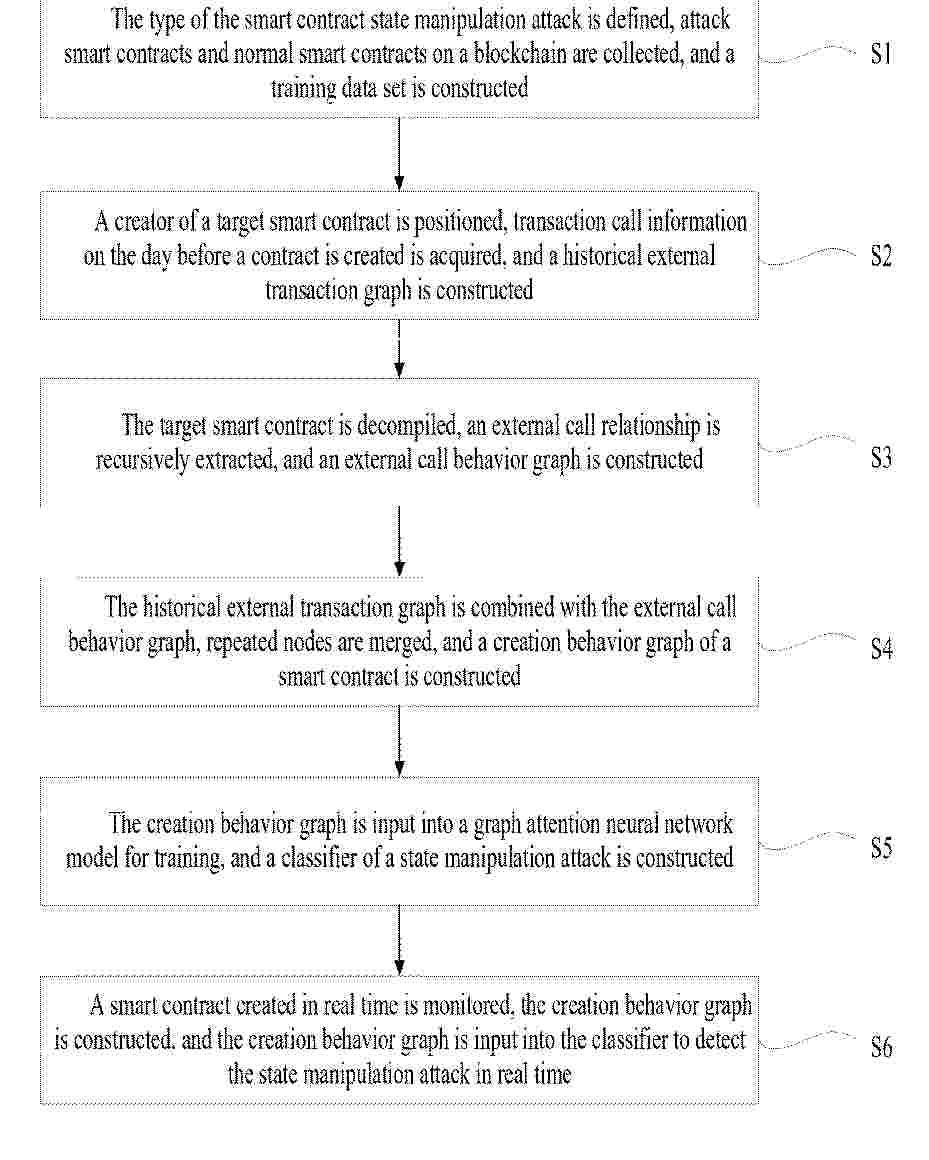
Provided are a method and a system for detecting a smart contract state manipulation attack based on a graph neural network, a device, and a medium, belonging to the technical field of blockchain security analysis. The method includes: defining the type of the smart contract state manipulation attack, collecting attack smart contracts and normal smart contracts on a blockchain, and constructing a training data set; positioning a creator of a target smart contract, and constructing a historical external transaction graph; decompiling the target smart contract, and constructing an external call behavior graph; combining the historical external transaction graph with the external call behavior graph, and constructing a creation behavior graph of a smart contract; constructing a classifier of a state manipulation attack; and monitoring a smart contract created in real time, constructing the creation behavior graph, and inputting the creation behavior graph into the classifier to detect the state manipulation attack in real time. Blockchain nodes can be connected, a newly deployed smart contract is acquired in real time, the creation behavior graph of the smart contract is constructed, and the creation behavior graph is input into a graph classification model to detect a state manipulation attack smart contract.
Resumen de: EP4831877A2
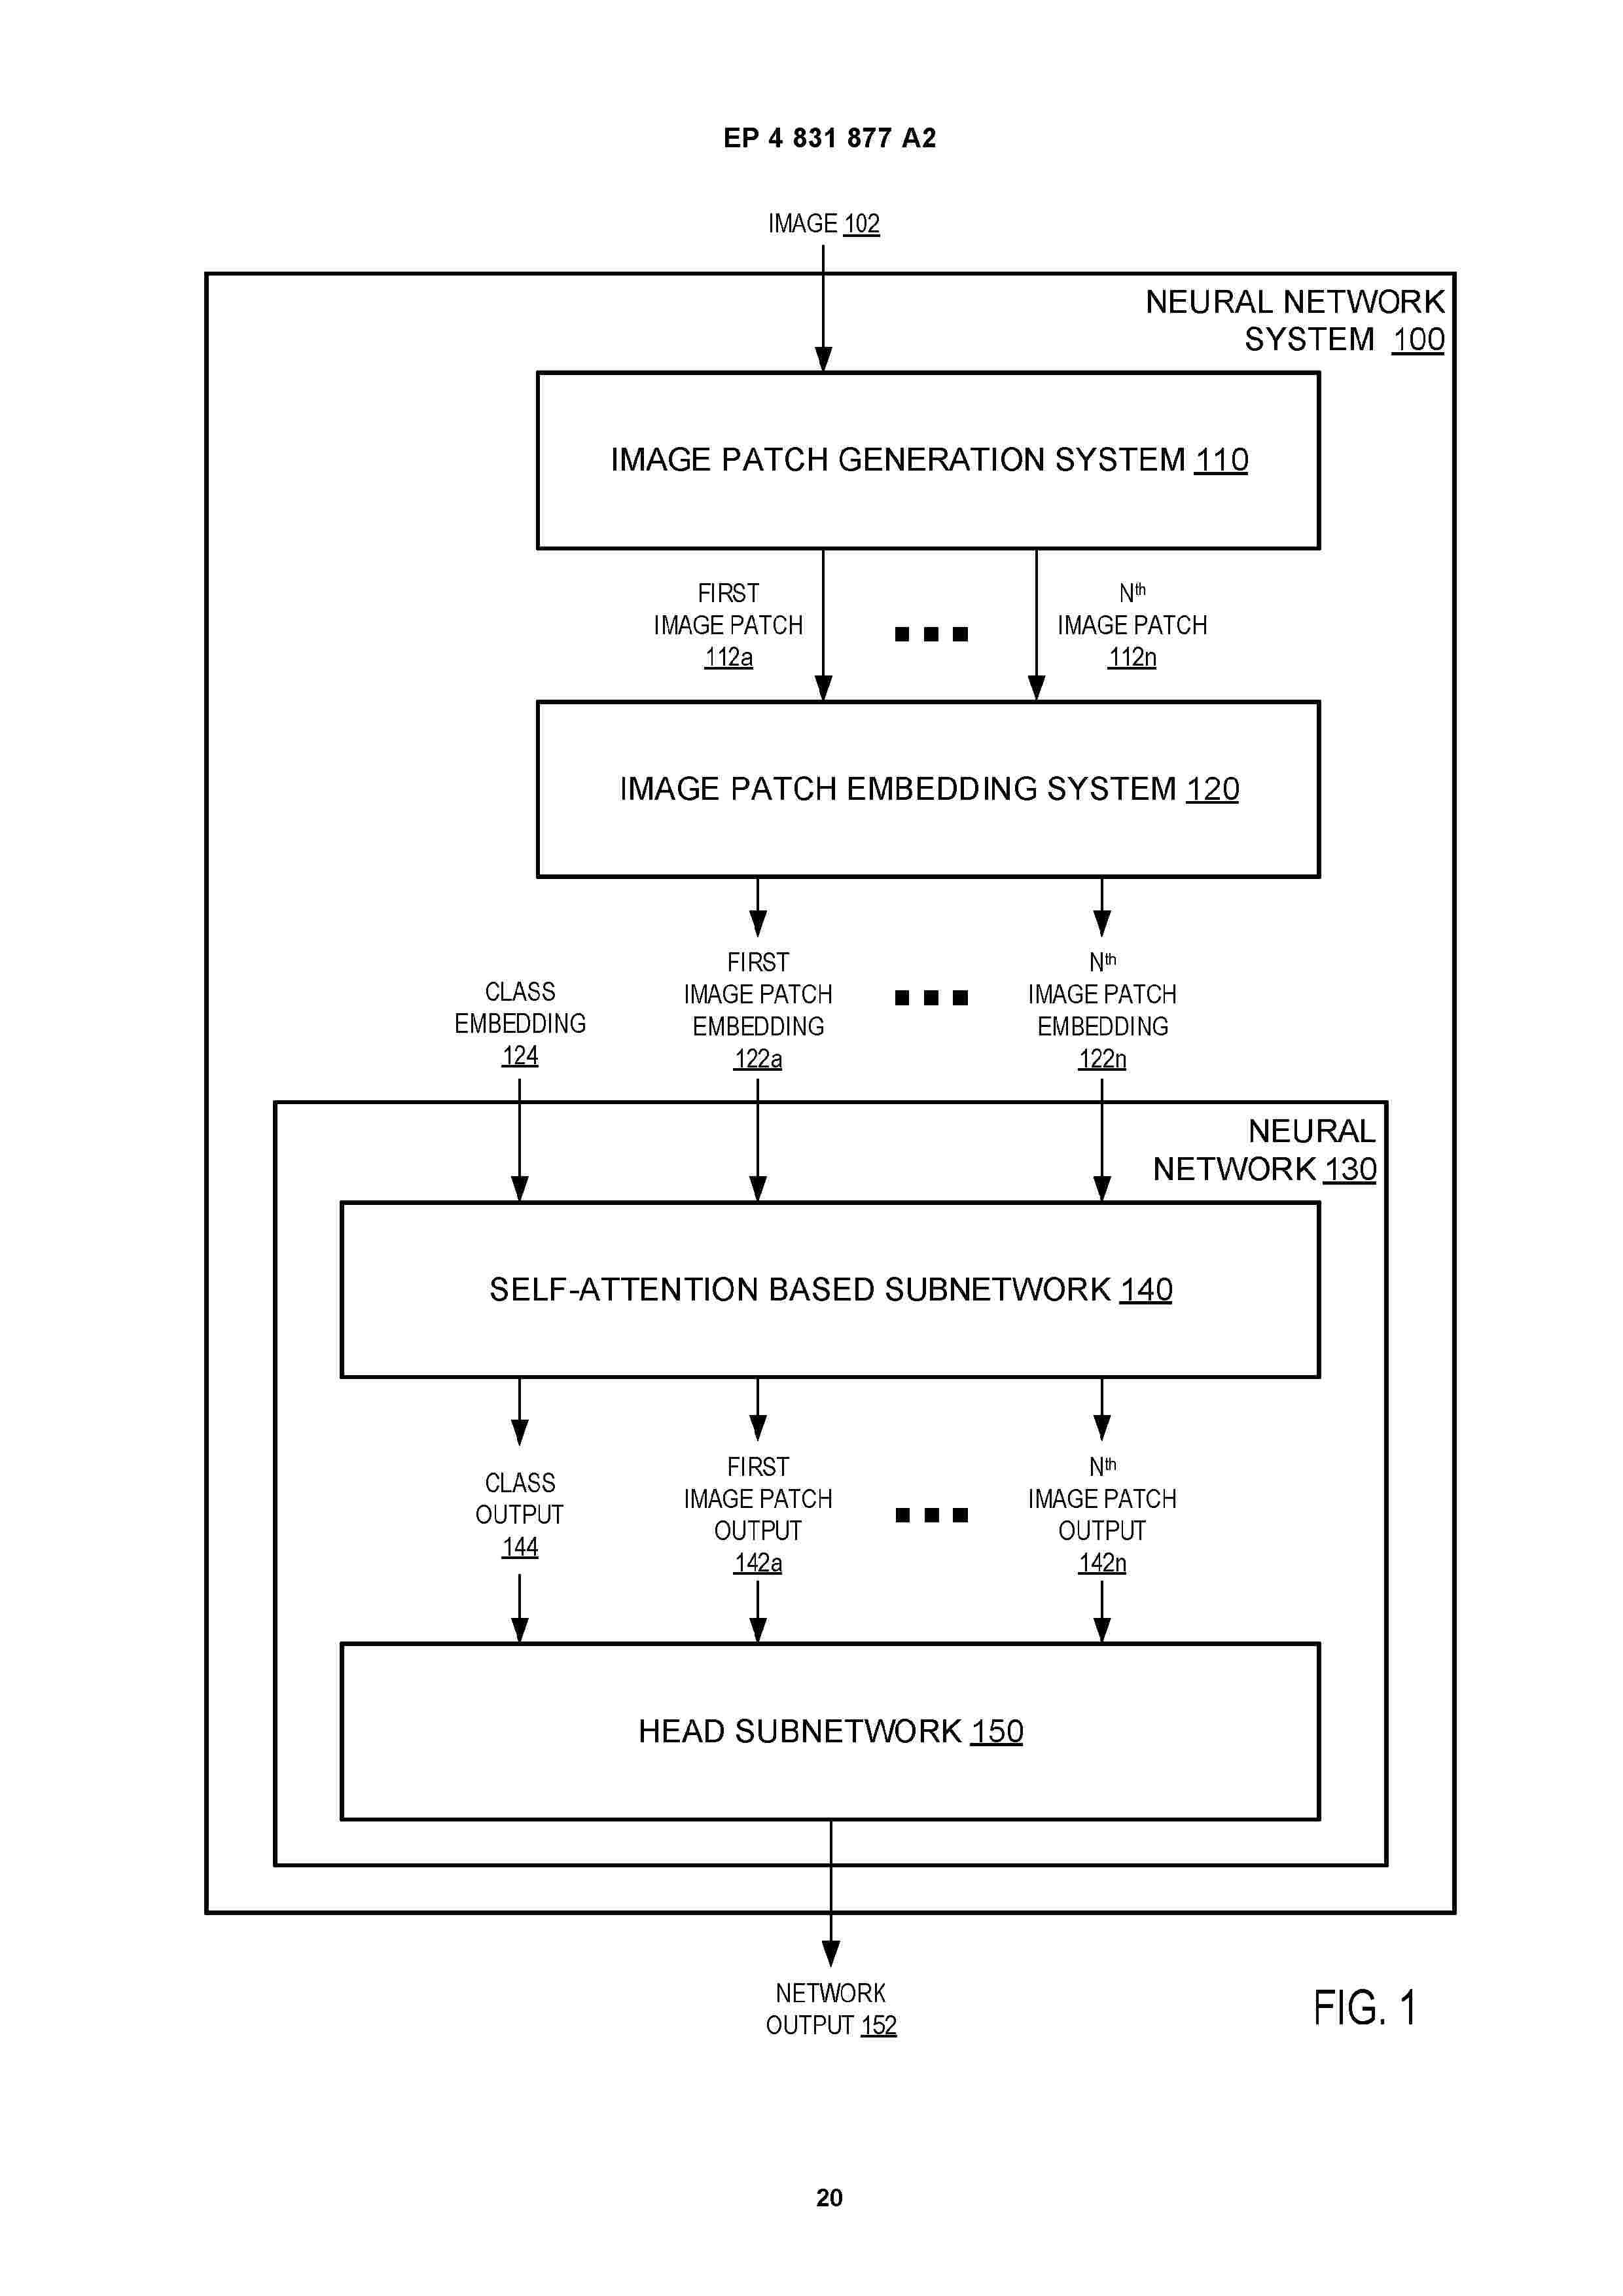
0001 Methods, systems, and apparatus, including computer programs encoded on computer storage media, for processing images using self-attention based neural networks. One of the methods includes obtaining one or more images comprising a plurality of pixels; determining, for each image of the one or more images, a plurality of image patches of the image, wherein each image patch comprises a different subset of the pixels of the image; processing, for each image of the one or more images, the corresponding plurality of image patches to generate an input sequence comprising a respective input element at each of a plurality of input positions, wherein a plurality of the input elements correspond to respective different image patches; and processing the input sequences using a neural network to generate a network output that characterizes the one or more images, wherein the neural network comprises one or more self-attention neural network layers.
Resumen de: EP4831935A1
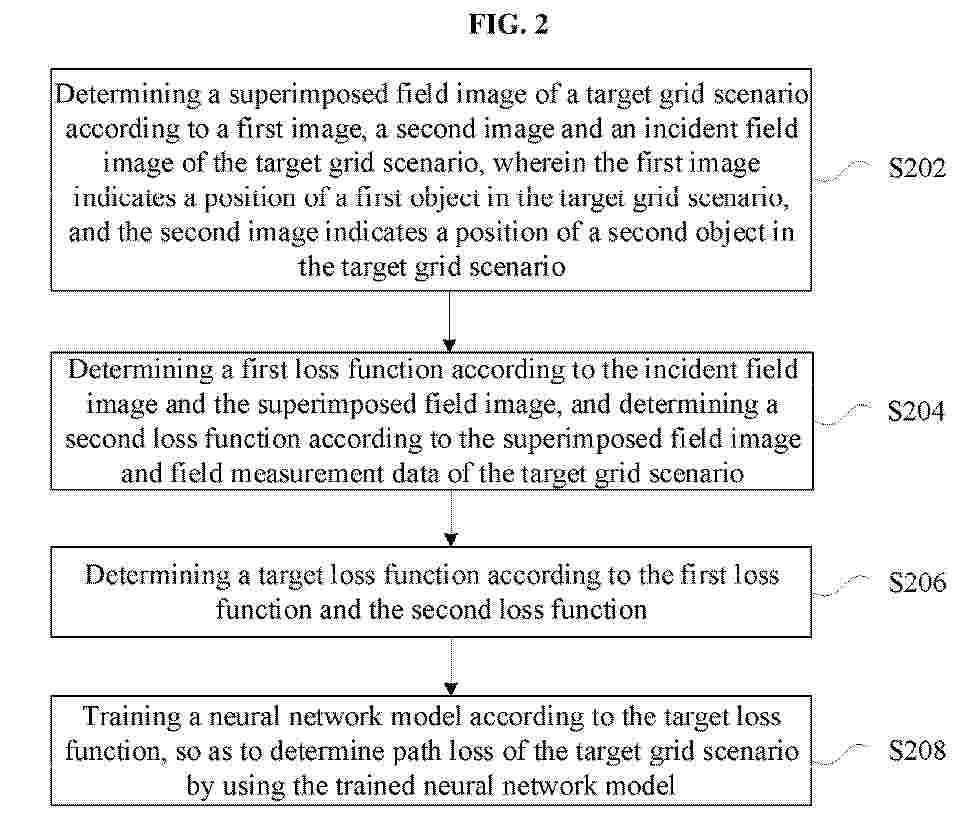
0001 A path loss determination method and apparatus, a storage medium, and an electronic device are provided. The method includes: determining (S202) a superimposed field image of a target grid scene on the basis of a first image, a second image, and an incident field image of the target grid scene; determining (S204) a first loss function on the basis of the incident field image and the superimposed field image, and determining (S204) a second loss function on the basis of the superimposed field image and drive test data of the target grid scene; determining (S206) a target loss function on the basis of the first loss function and the second loss function; and training (S208) a neural network model on the basis of the target loss function, so as to determine the path loss of the target grid scene by means of the trained neural network model.
Resumen de: EP4831881A1
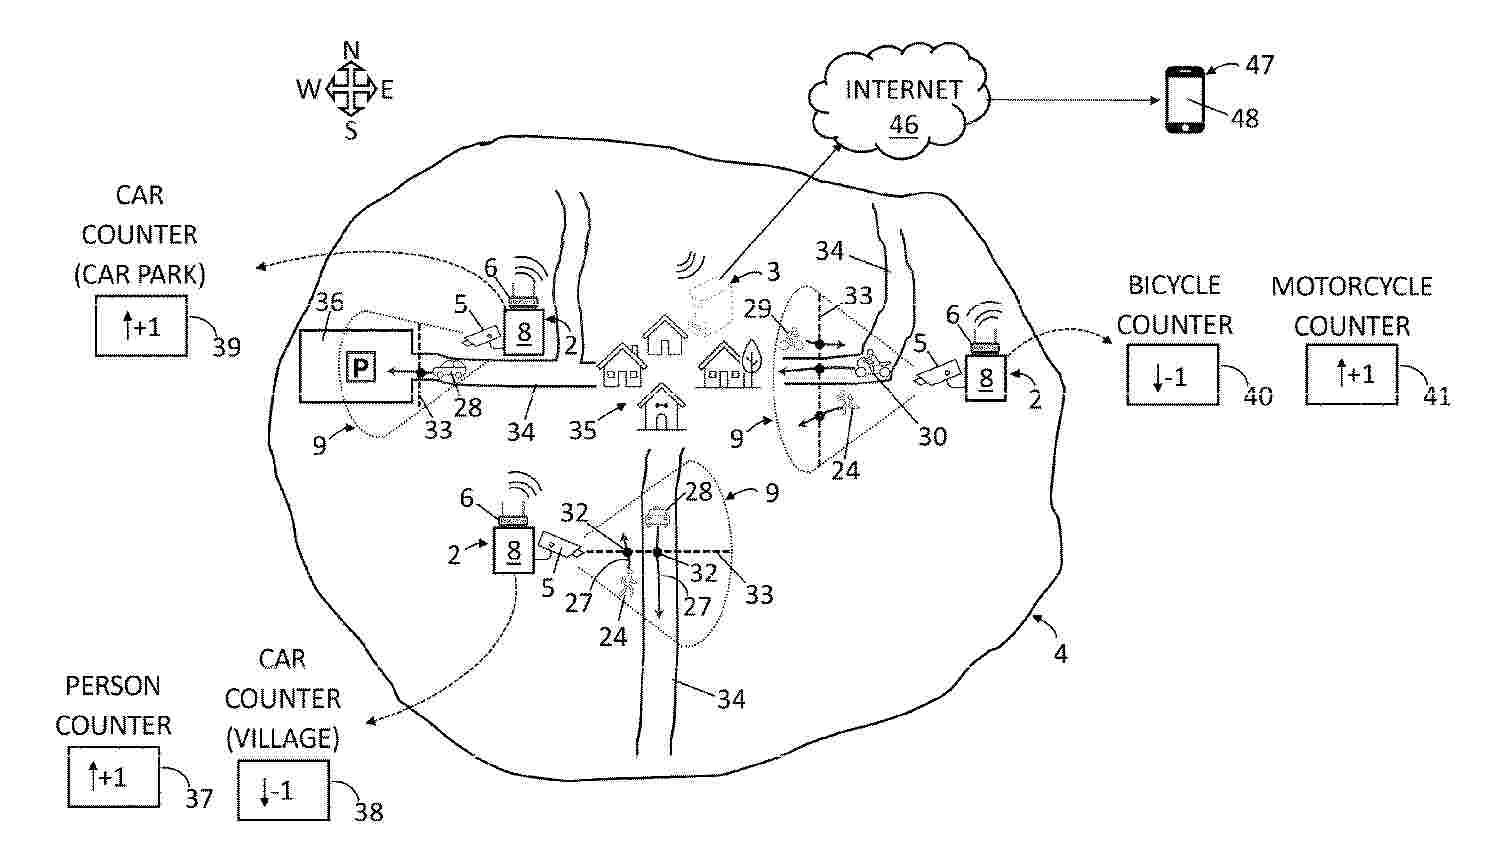
System and method for monitoring mixed flows of people and vehicles in rural and natural environments. The system comprises person and vehicle detection devices (2) equipped with a millimetre-wave radar (5) and a data processing unit (8) the purpose of which is to:- classify the moving point cloud (10) of each radar scan using a previously trained artificial neural network (18) that receives as input the distance (12), the azimuth angle (13), the elevation angle (14), the Doppler velocity (15), and the signal-to-noise ratio (16) of each point (11) in the cloud of moving points (10), to yield a list (20) of targets classified by type (23) as a person (24) or a specific vehicle (28, 29, 30) from a list of vehicles (25),- determine a trajectory (27) for each target (21),- count each type (23) of target the trajectory (27) of which crosses a counting line (33).A central server (3) monitors the flows of each type (23) of target using the count information (42).
Resumen de: US20260330826A1
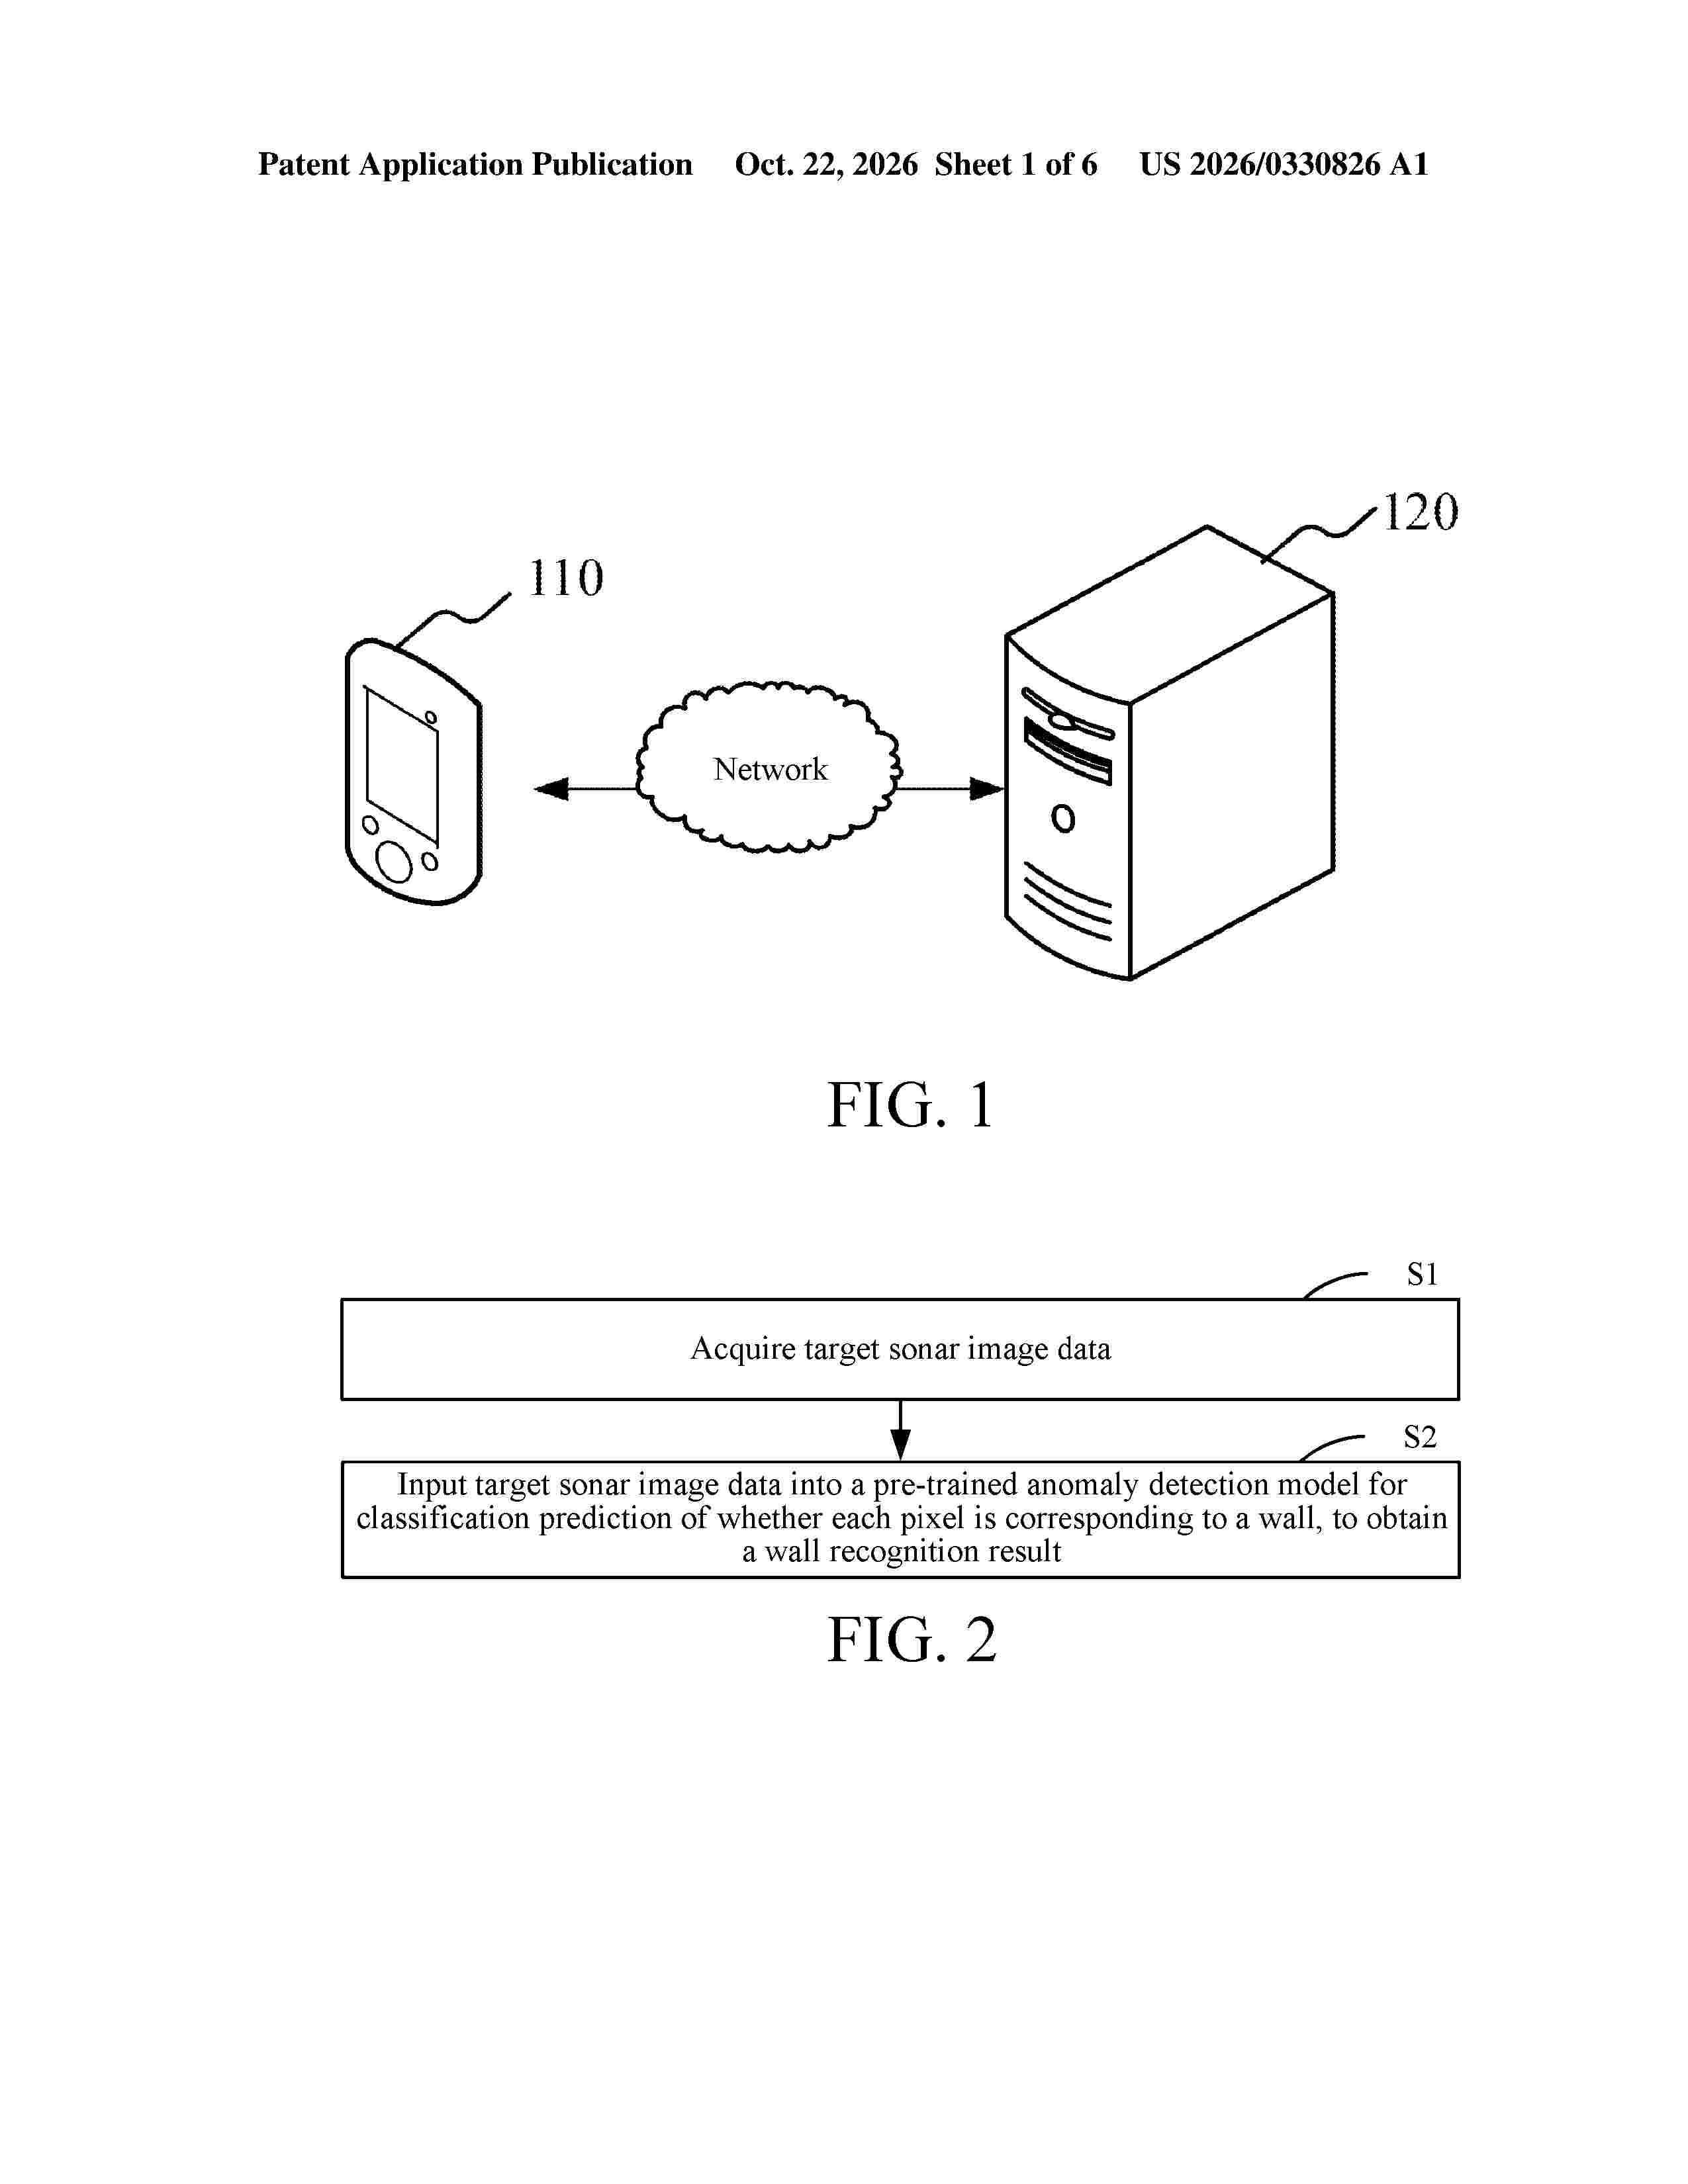
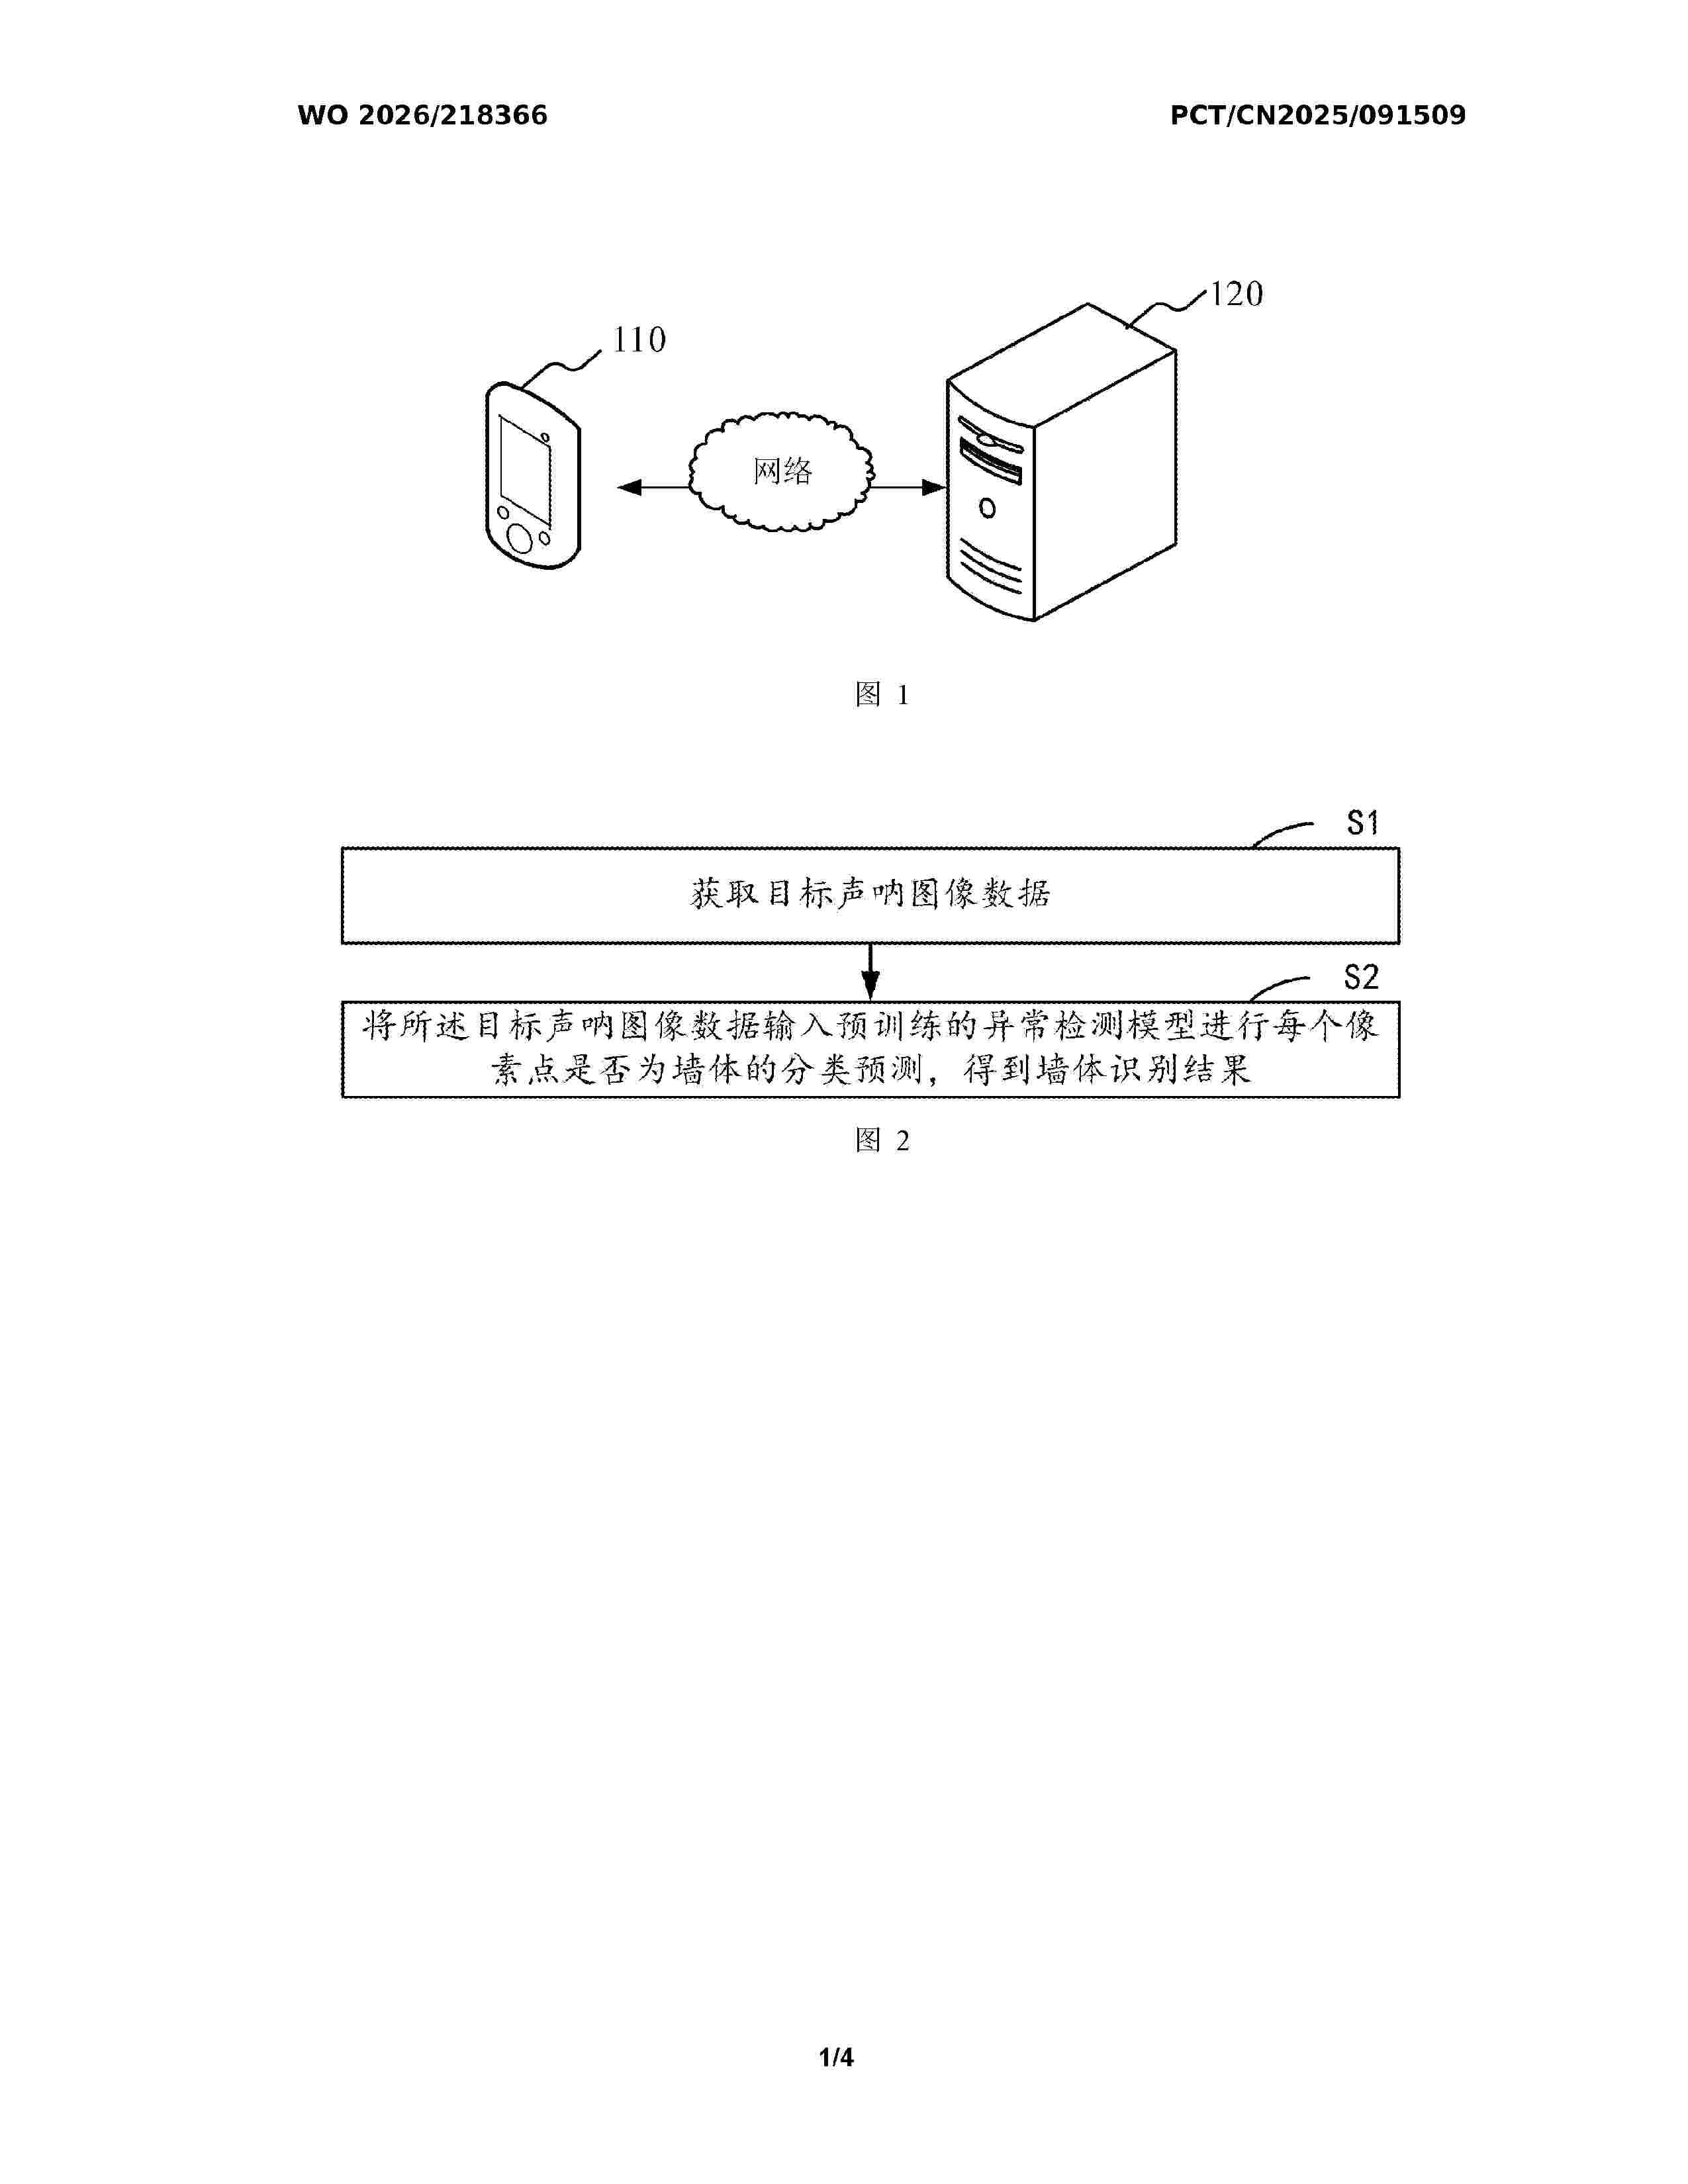
0000 This application relates to the field of sonar technology and discloses a wall recognition method and system for a sonar image, a device, and a storage medium. The method includes: inputting target sonar image data into a pre-trained anomaly detection model for classification prediction of whether each pixel is corresponding to a wall, to obtain a wall recognition result, where training steps for the anomaly detection model include: acquiring training data, using the training data to train an initial model for classification prediction of whether each pixel is corresponding to a wall, to obtain the anomaly detection model, where an anomaly detection network based on a convolutional neural network (CNN) is used for the initial model, and the training data includes sonar image sample data and a target label matrix. accurate presentation of various wall details, and improved wall recognition accuracy.
Resumen de: US20260330230A1
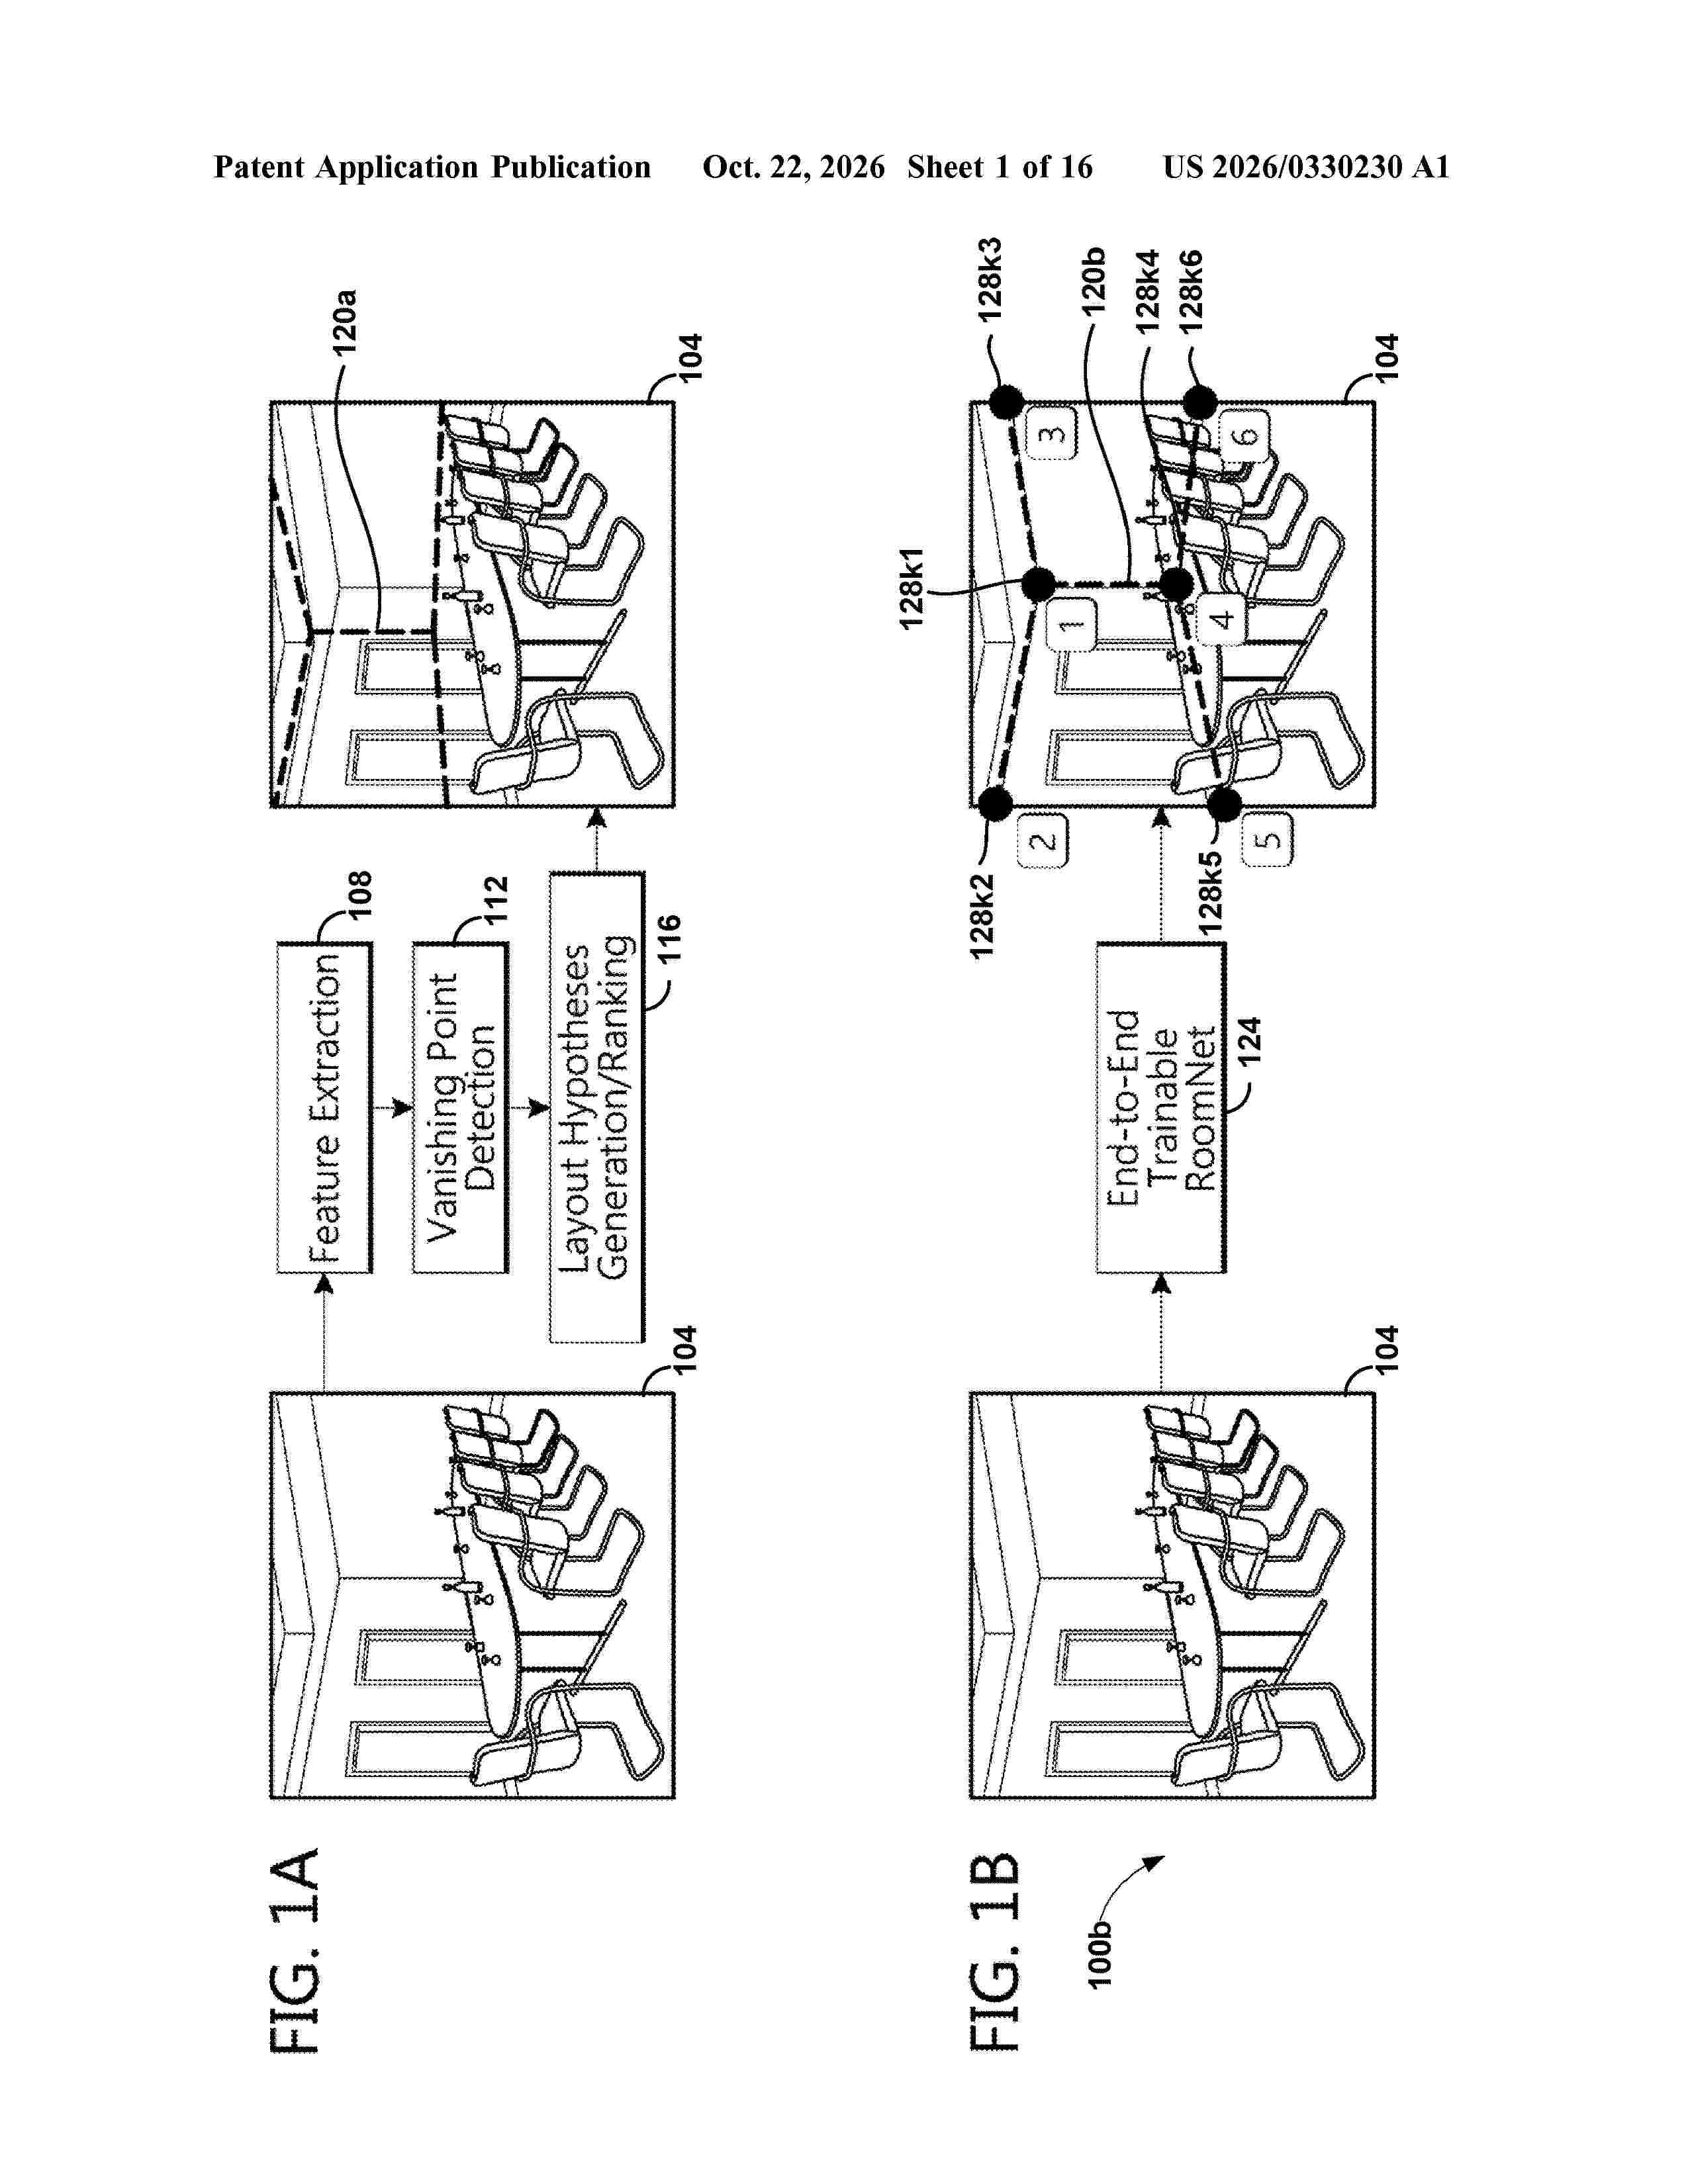
A non-transitory computer-readable medium storing instructions that, when executed by one or more computers, cause the one or more computers to: access a room image of a room for room layout estimation; determine, using an encoder-decoder sub-network of a neural network for estimating a layout of a room and the room image, a plurality of predicted two-dimensional (2D) keypoint maps corresponding to a plurality of room types; determine, using the encoder-decoder sub-network, a classifier sub-network of the neural network connected to the encoder-decoder sub-network, and the room image, a predicted room type from the plurality of room types; determine, using the plurality of predicted 2D keypoint maps and the predicted room type, a plurality of ordered keypoints associated with the predicted room type; and determine, using the plurality of ordered keypoints, a predicted layout of the room in the room image.
Resumen de: WO2026222472A1
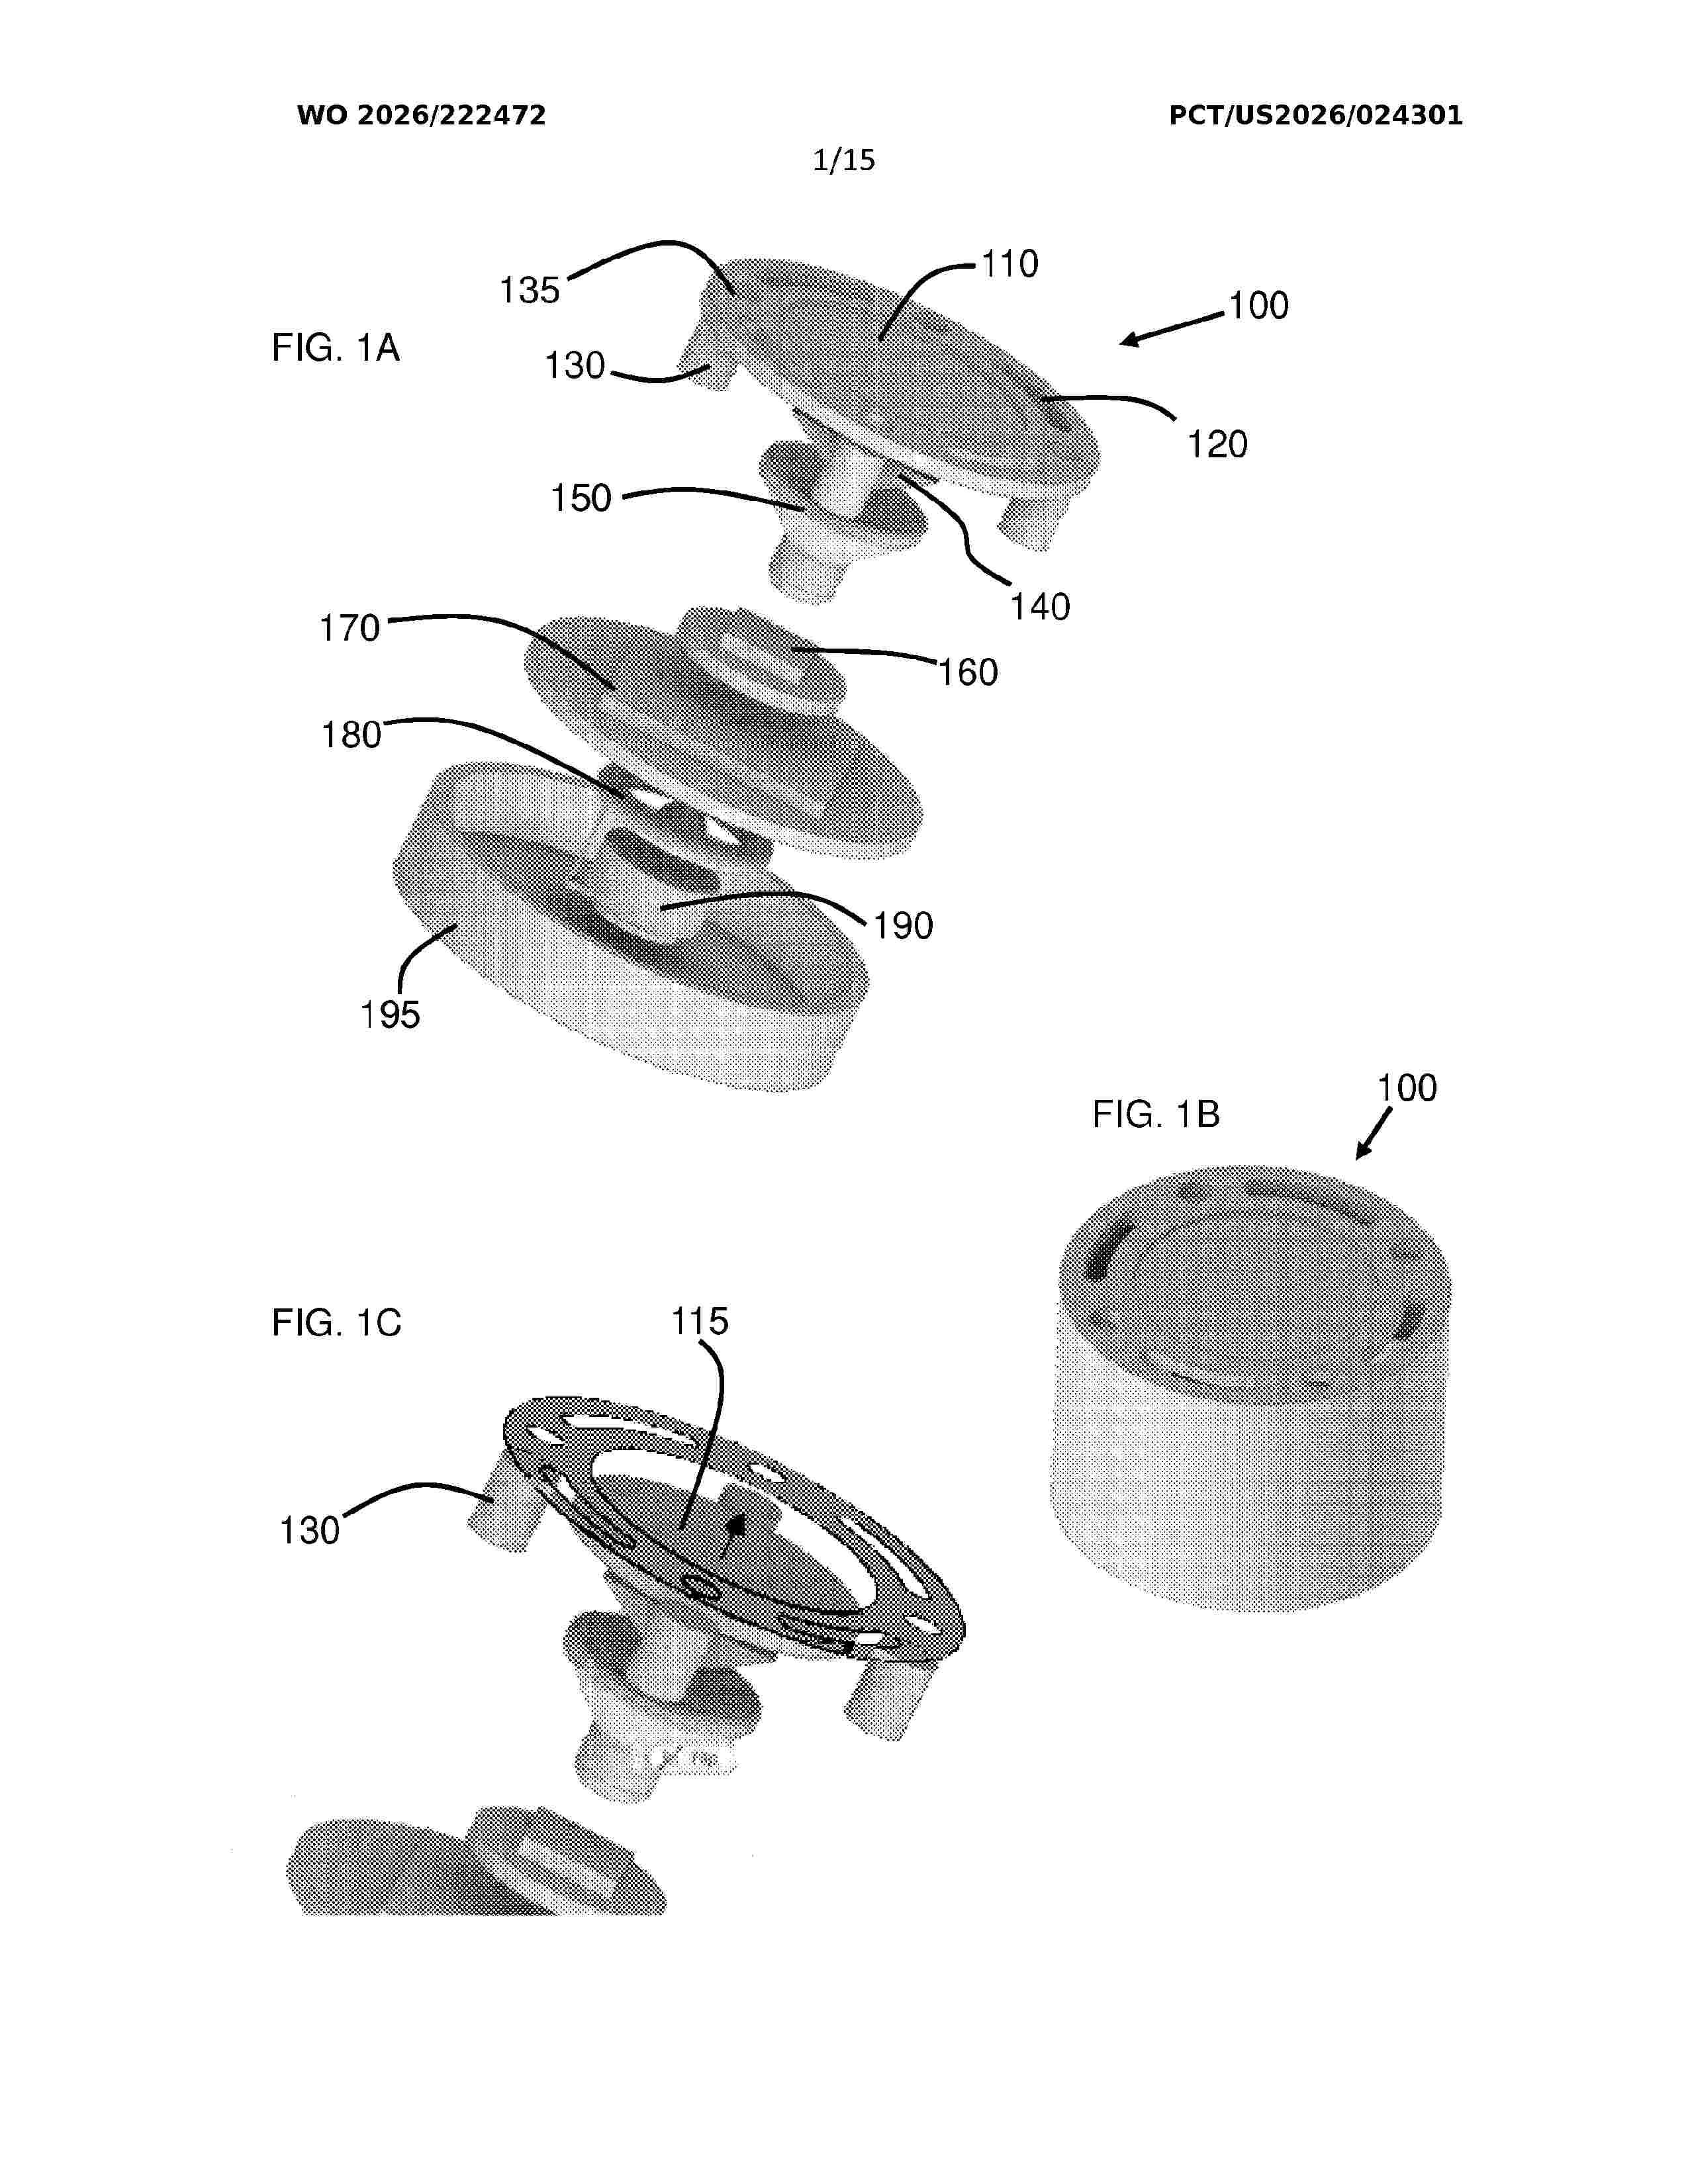
An artificial intelligence device (AID) is disclosed that is configured for a specific, predetermined use case and is operable without access to a remote server during normal operation. The AID comprises a processor, a first memory storing at least one AI decision matrix comprising trained neural network weight values, a database storing response templates and vocabulary data, one or more microphones, and a user interface including a touchscreen and speaker. The processor applies the AI decision matrices to user input signals to generate analysis results and constructs responses by querying the database. The AI decision matrices are derived through a supervised training process. The AID may include a self-erase routine triggered by tamper detection, timer expiration, or remote command. A system and methods for operating and training the AID are also disclosed.
Resumen de: WO2026218787A1
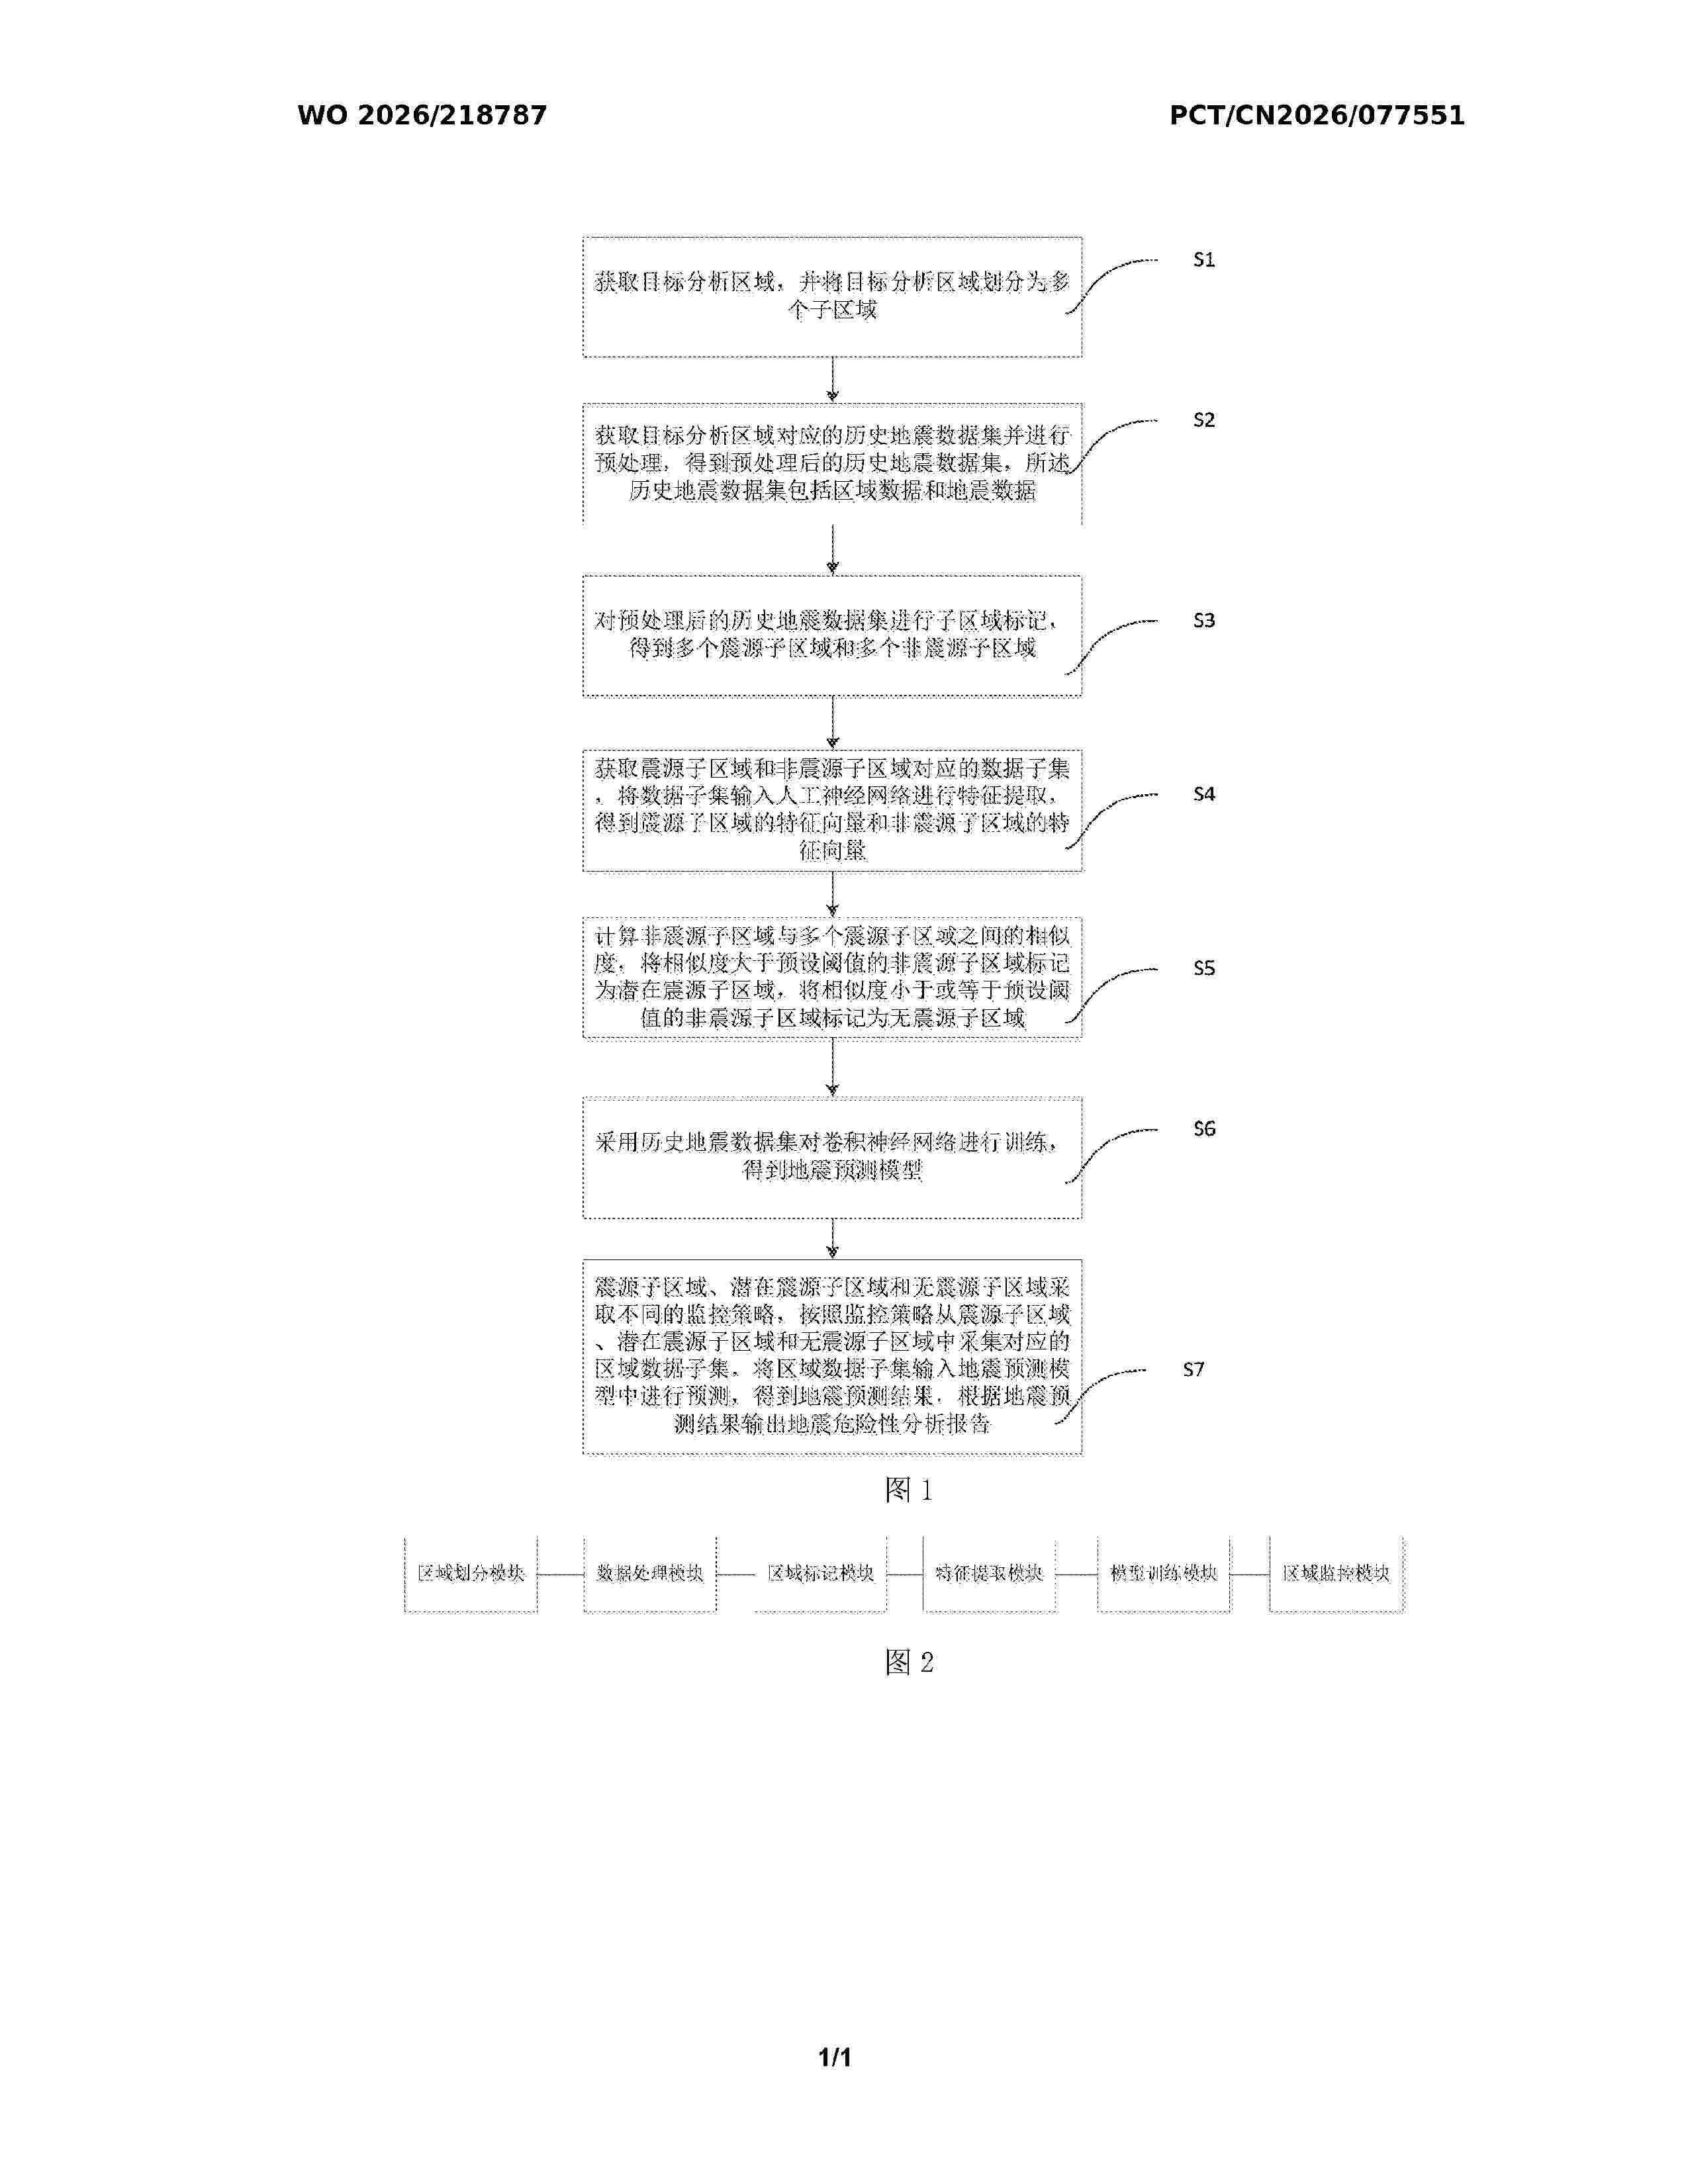
Disclosed in the present invention is a natural earthquake hazard analysis method based on an artificial neural network, the method comprising: S1, acquiring a target analysis region, and dividing the target analysis region into a plurality of sub-regions; S2, acquiring a historical earthquake dataset corresponding to the target analysis region and performing preprocessing; S3, performing sub-region labeling on the preprocessed dataset to obtain a plurality of focus sub-regions and non-focus sub-regions; S4, acquiring data subsets corresponding to the focus sub-regions and the non-focus sub-regions, and inputting the data subsets into an artificial neural network for feature extraction; S5, calculating the similarities between the non-focus sub-regions and the plurality of focus sub-regions; S6, using the historical earthquake dataset to train a convolutional neural network, so as to obtain an earthquake prediction model; and S7, inputting the data subsets of different regions into the earthquake prediction model for prediction, so as to obtain an earthquake prediction result, and outputting an earthquake hazard analysis report on the basis of the earthquake prediction result. The method realizes earthquake hazard analysis for multiple regions and potential earthquake regions.
Nº publicación: WO2026218366A1 22/10/2026
Solicitante:
ZHEJIANG OCEAN UNIV [CN]
HAIZHUOKE ZHEJIANG FREE TRADE ZONE TECH CO LTD [CN]
\u6D59\u6C5F\u6D77\u6D0B\u5927\u5B66
\u6D77\u5353\u79D1\uFF08\u6D59\u6C5F\u81EA\u8D38\u533A\uFF09\u79D1\u6280\u6709\u9650\u516C\u53F8
Resumen de: WO2026218366A1
The present application relates to the technical field of sonar, and discloses a method and system for wall recognition in a sonar image, a device, and a storage medium. The method comprises: inputting target sonar image data into a pre-trained anomaly detection model to perform classification prediction of whether each pixel is a wall, so as to obtain a wall recognition result. Training steps of the anomaly detection model comprise: acquiring training data, and using the training data to train an initial model for classification prediction of whether each pixel is a wall, so as to obtain the anomaly detection model, wherein the initial model uses an anomaly detection network based on a convolutional neural network, and the training data comprises sonar image sample data and a target label matrix. The anomaly detection model in the present application directly performs classification recognition of whether each pixel is a wall. By means of pixel-level classification, a wall can be recognized more accurately, the contour of the wall can be outlined more precisely, and various details of the wall are accurately presented, thereby improving the accuracy of wall recognition.
 BOPI
 Sede Electrónica